Flexible-Joint Robot Control.
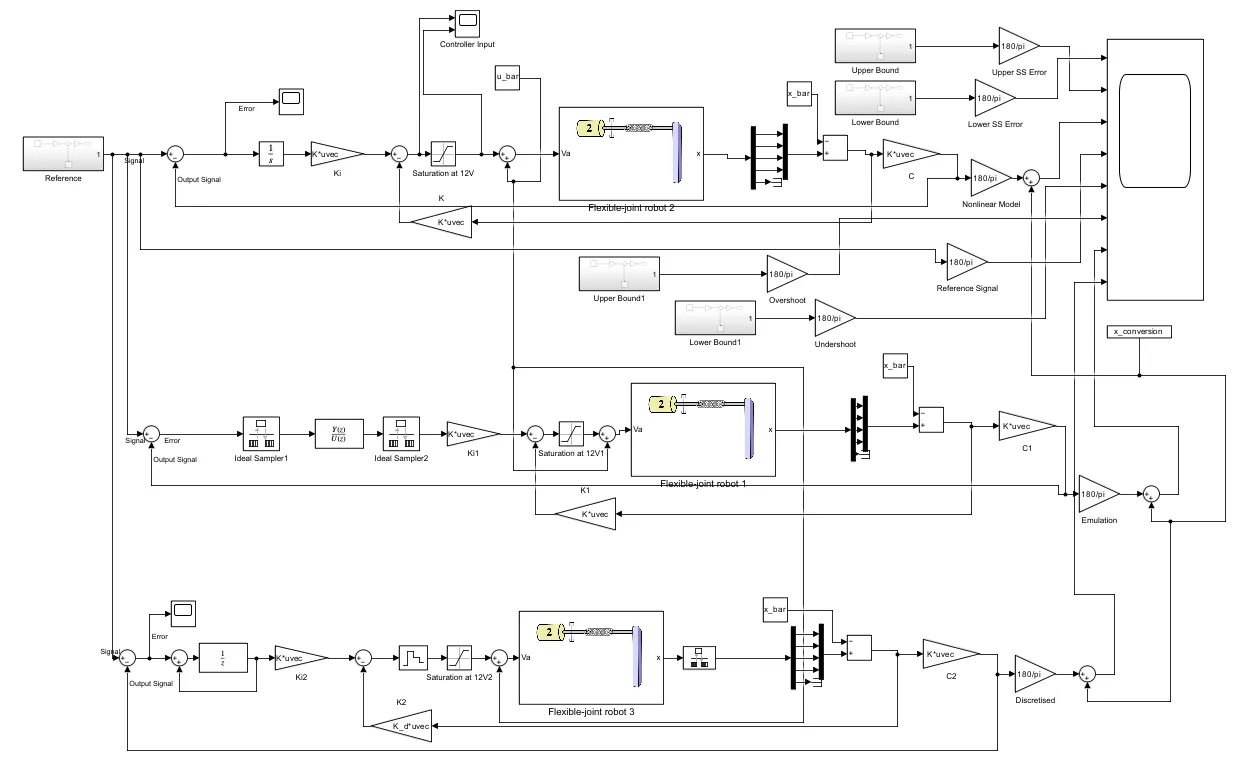
Classical, state-space and optimal controllers for a single-link flexible-joint robot, designed and tested in a high-fidelity Simulink model.
Reports
Highlights
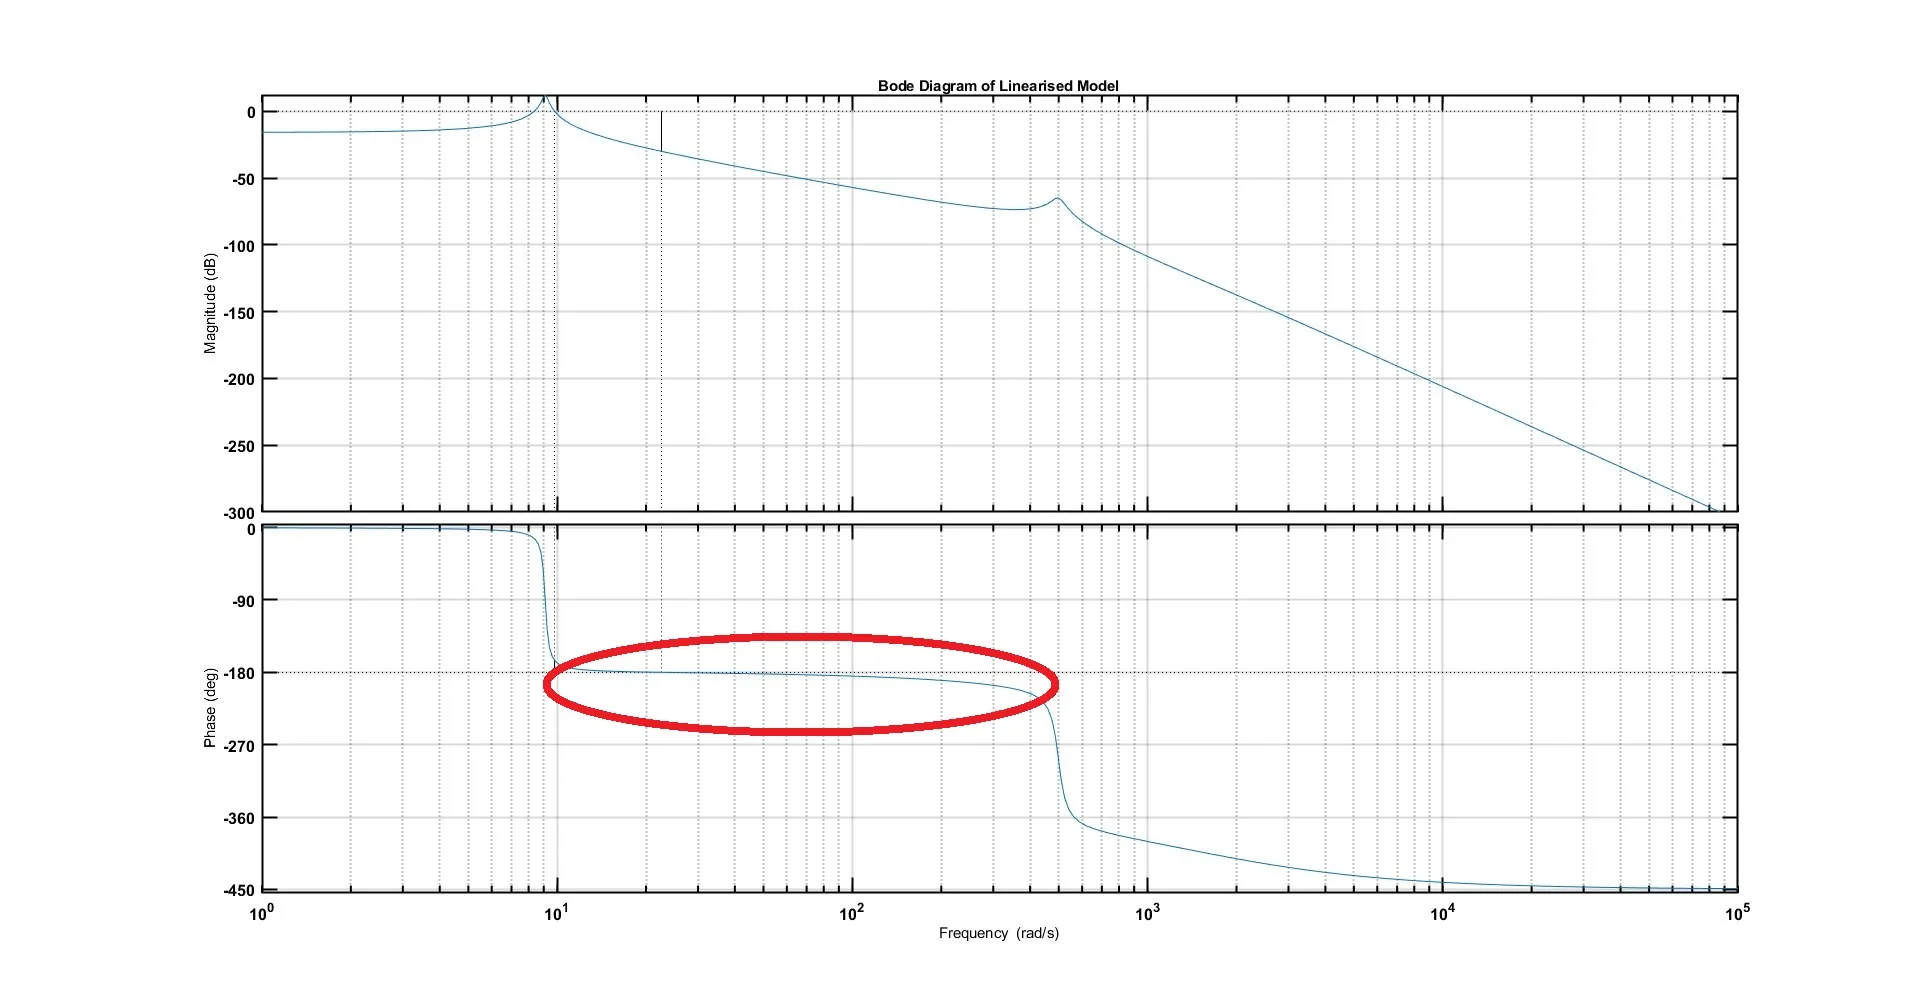
Classical.
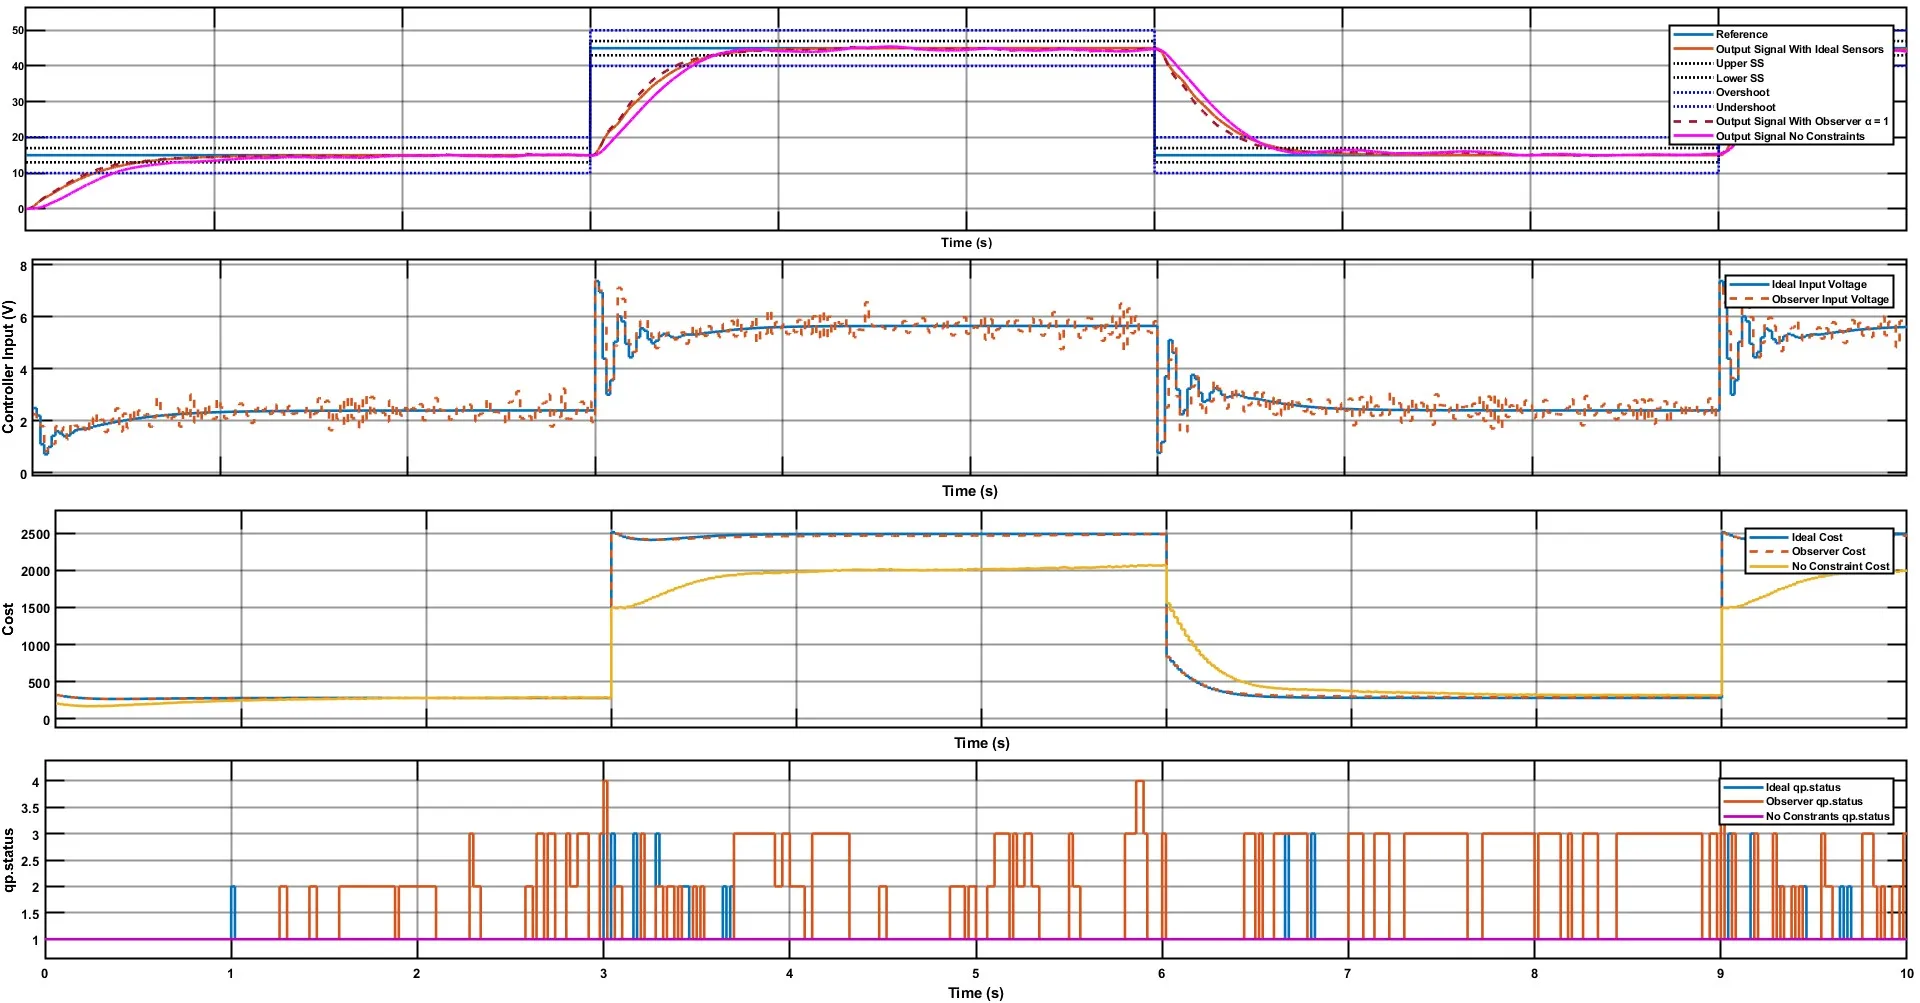
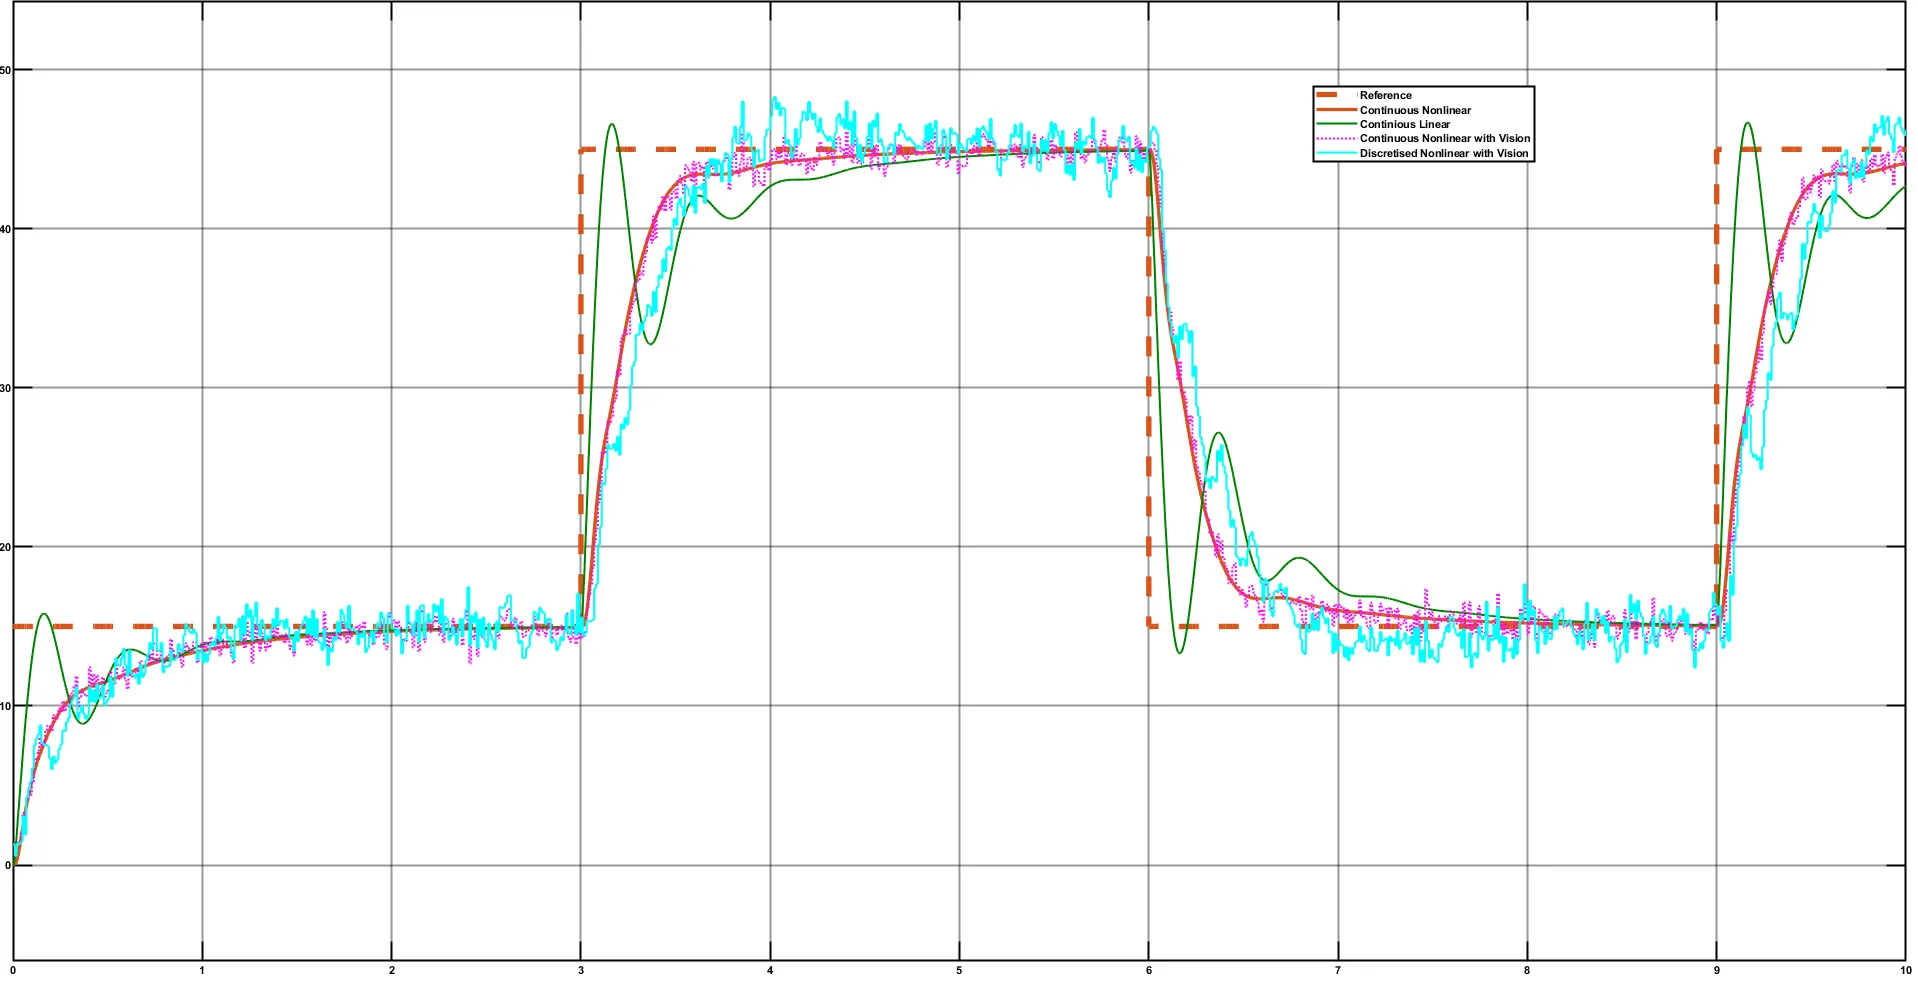
The brief: swing the arm between 15° and 45° every 3 seconds with at most 2° steady-state error, 5° overshoot and a 2-second settling time, sampling at no more than 50 Hz.
Observers.
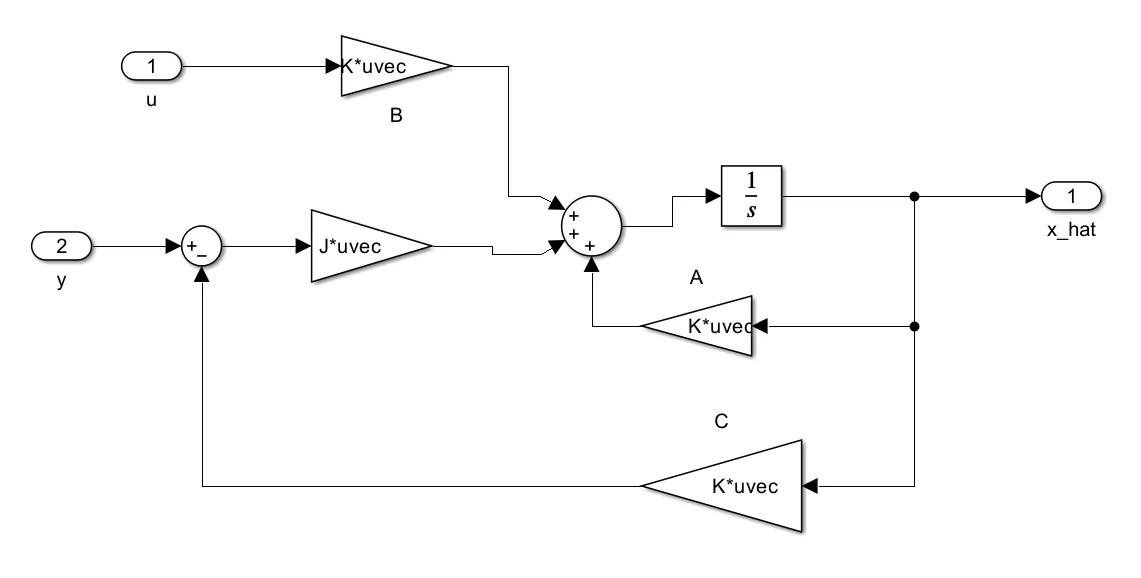
Pole placement used to design continuous and discrete full-state and reduced-order observers, compared across motor and sensor combinations.
Optimal.
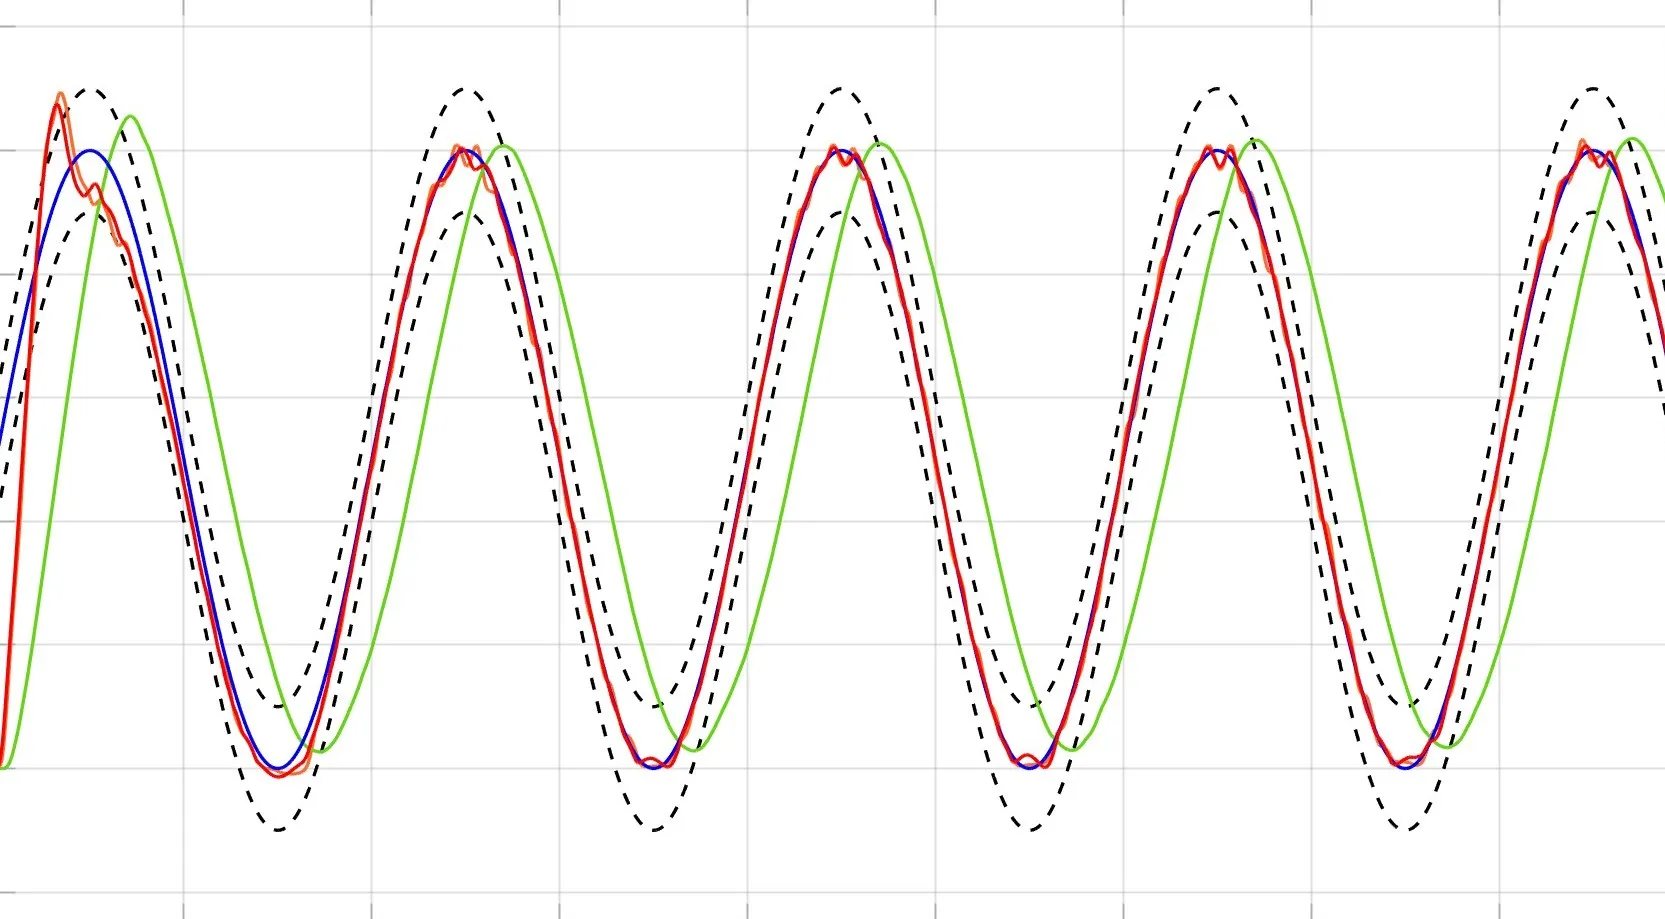
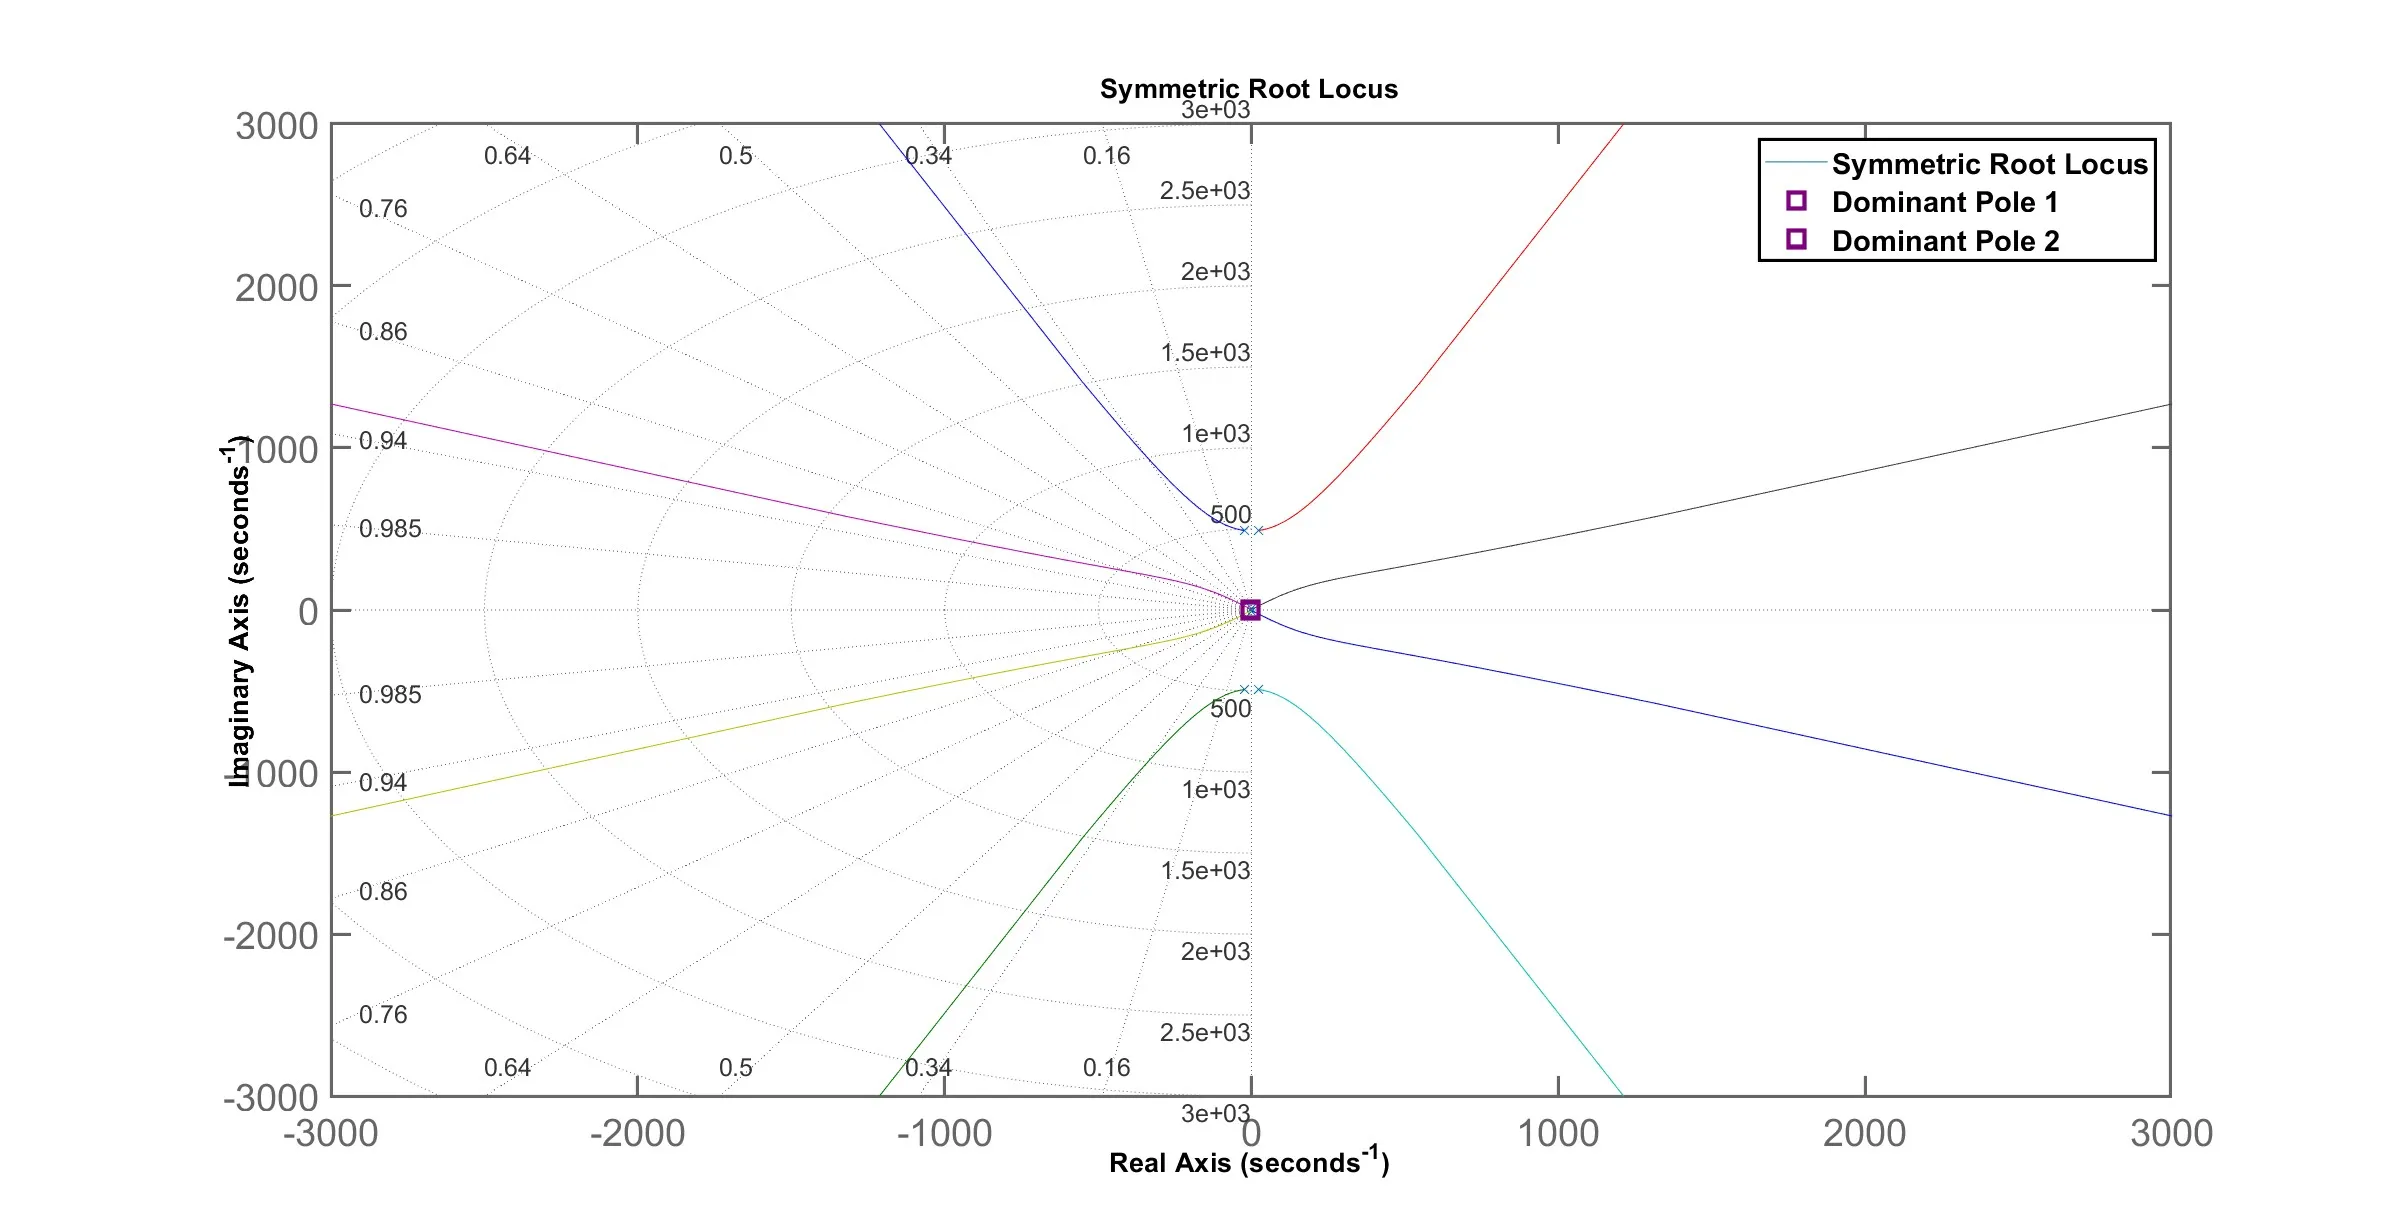
An LQR controller designed with the symmetric root locus and Riccati equation, then an LQG controller that handles a sinusoidal input disturbance.