Robotics and Automation.
Key skills.
ROS2 systems
ROS2 Humble and Python systems that link physical hardware to simulation.
Computer vision
OpenCV for object detection, target tracking, 3D reconstruction, SLAM, camera calibration and behaviour analysis.
Trajectory planning
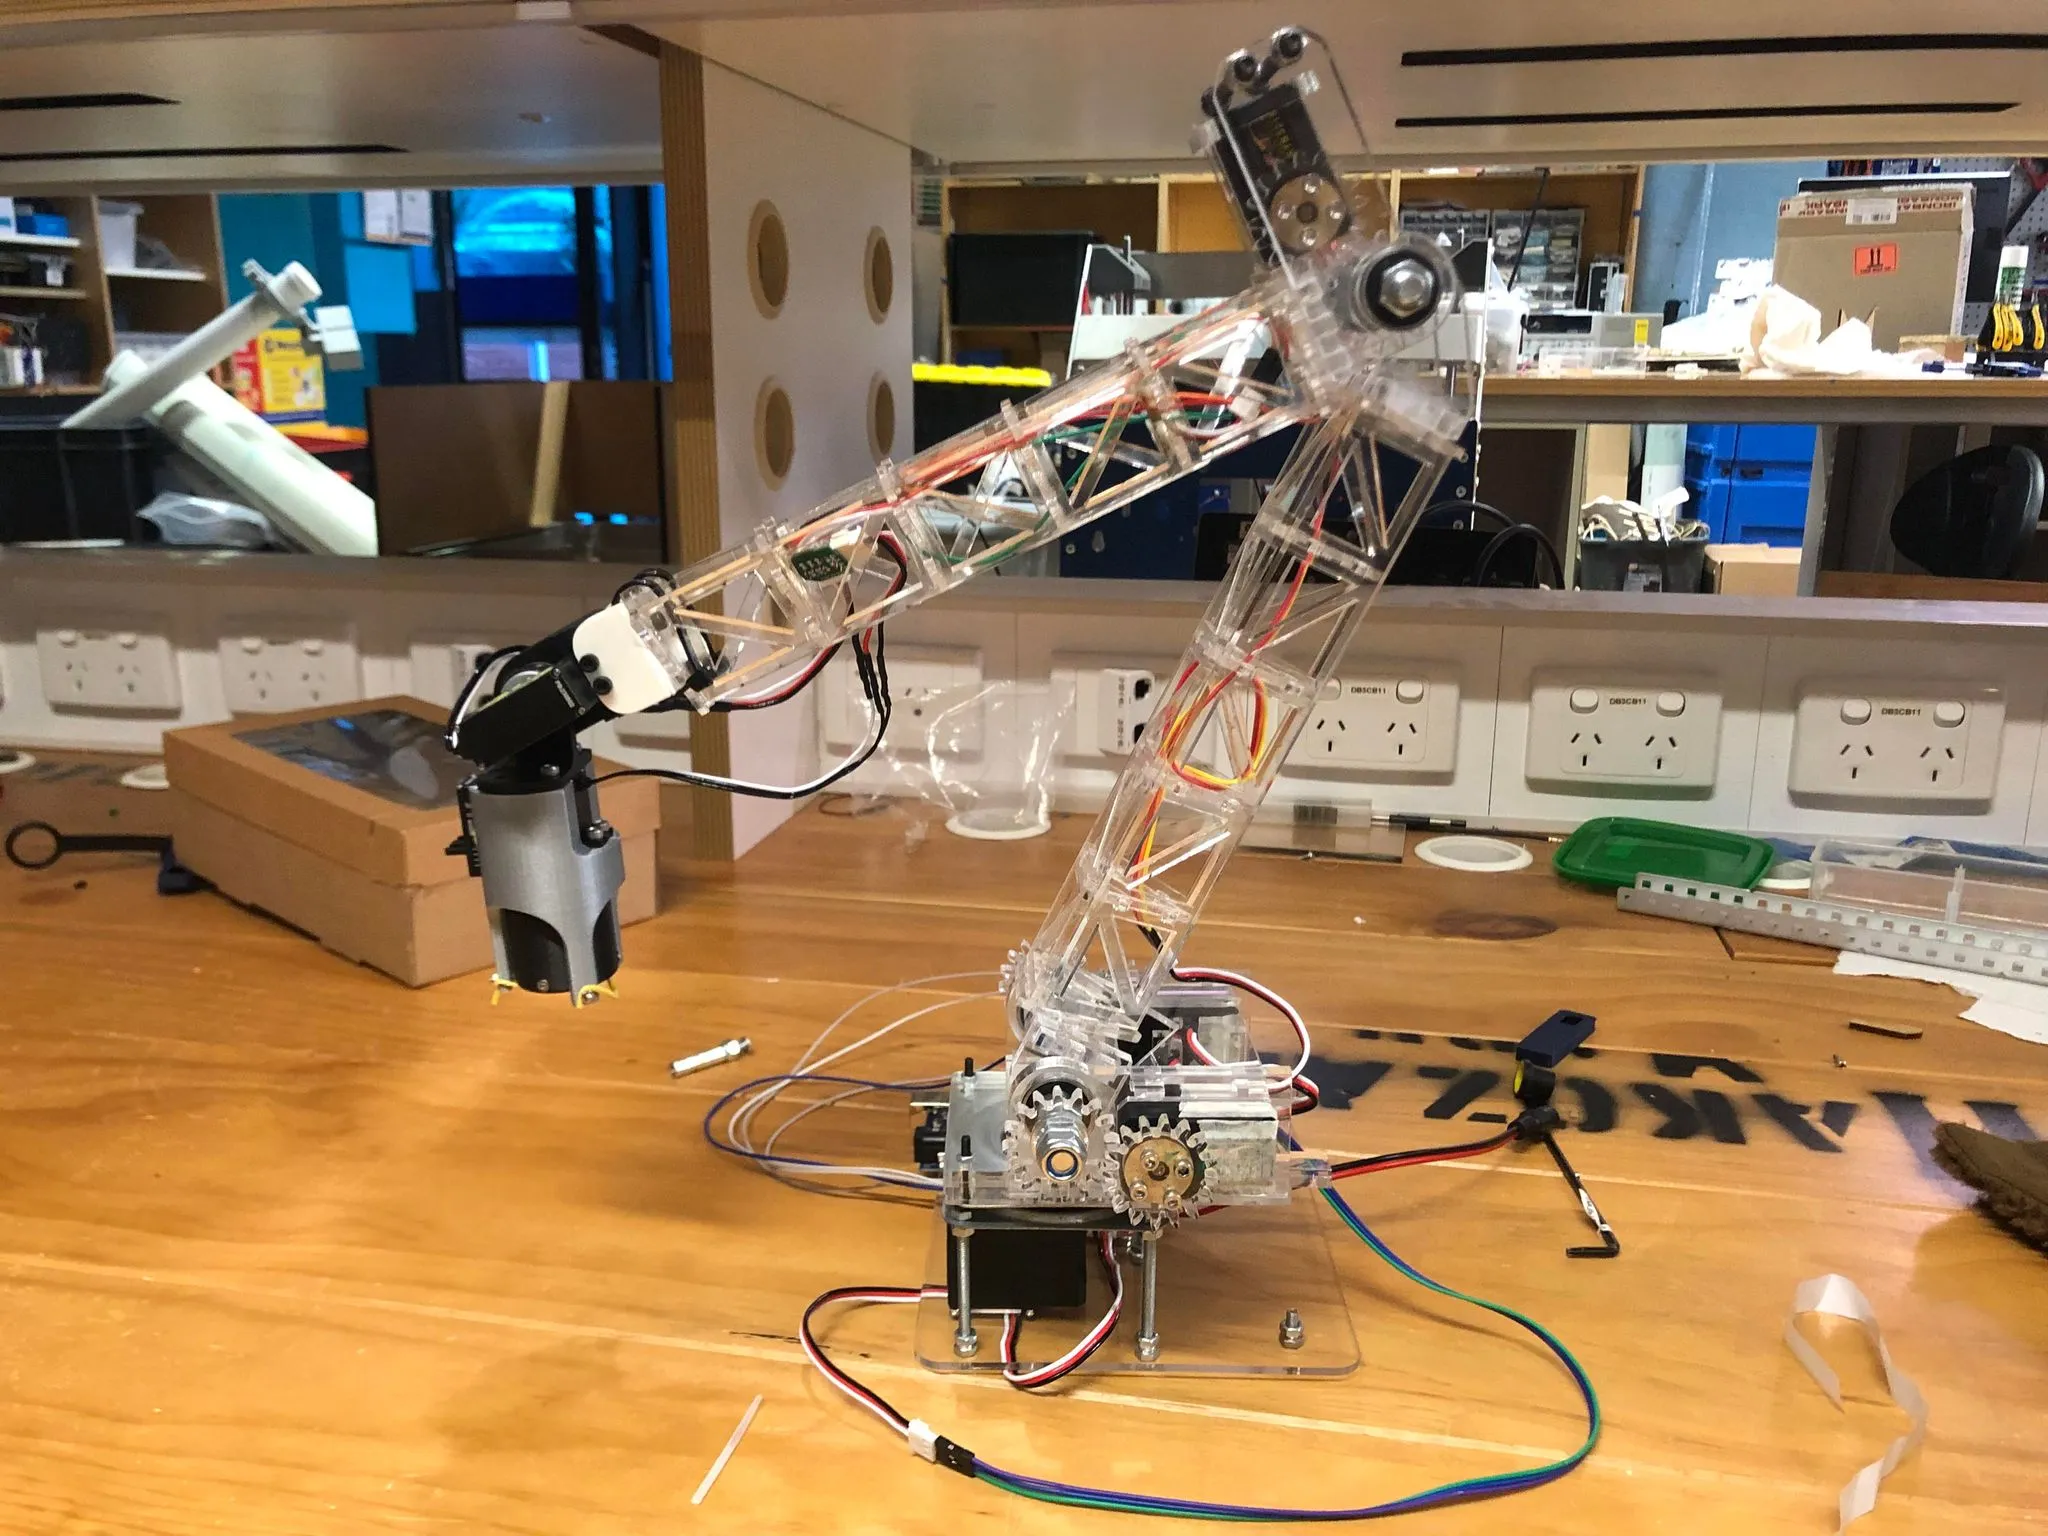
Planning robot trajectories so manipulators move smoothly between poses.
Control design
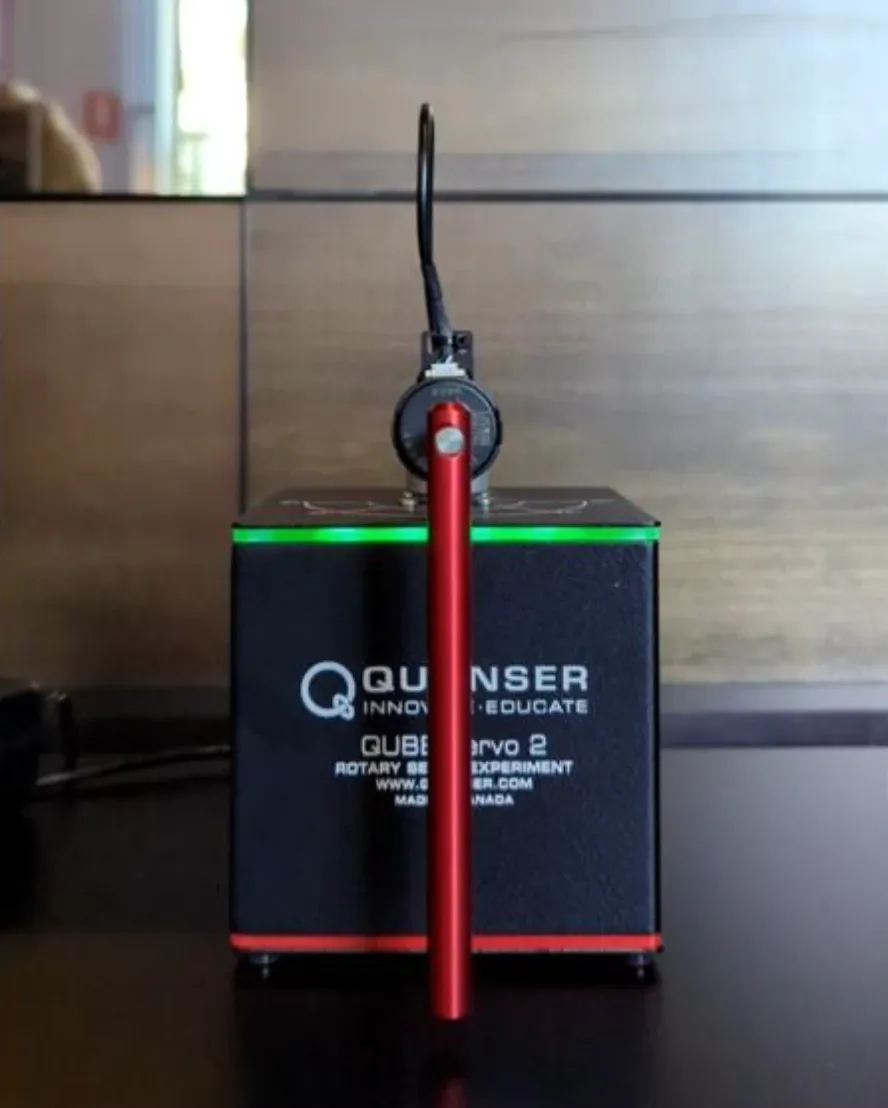
Controllers and observers built with classical and modern control theory, then tested in Simulink models.
Simulation
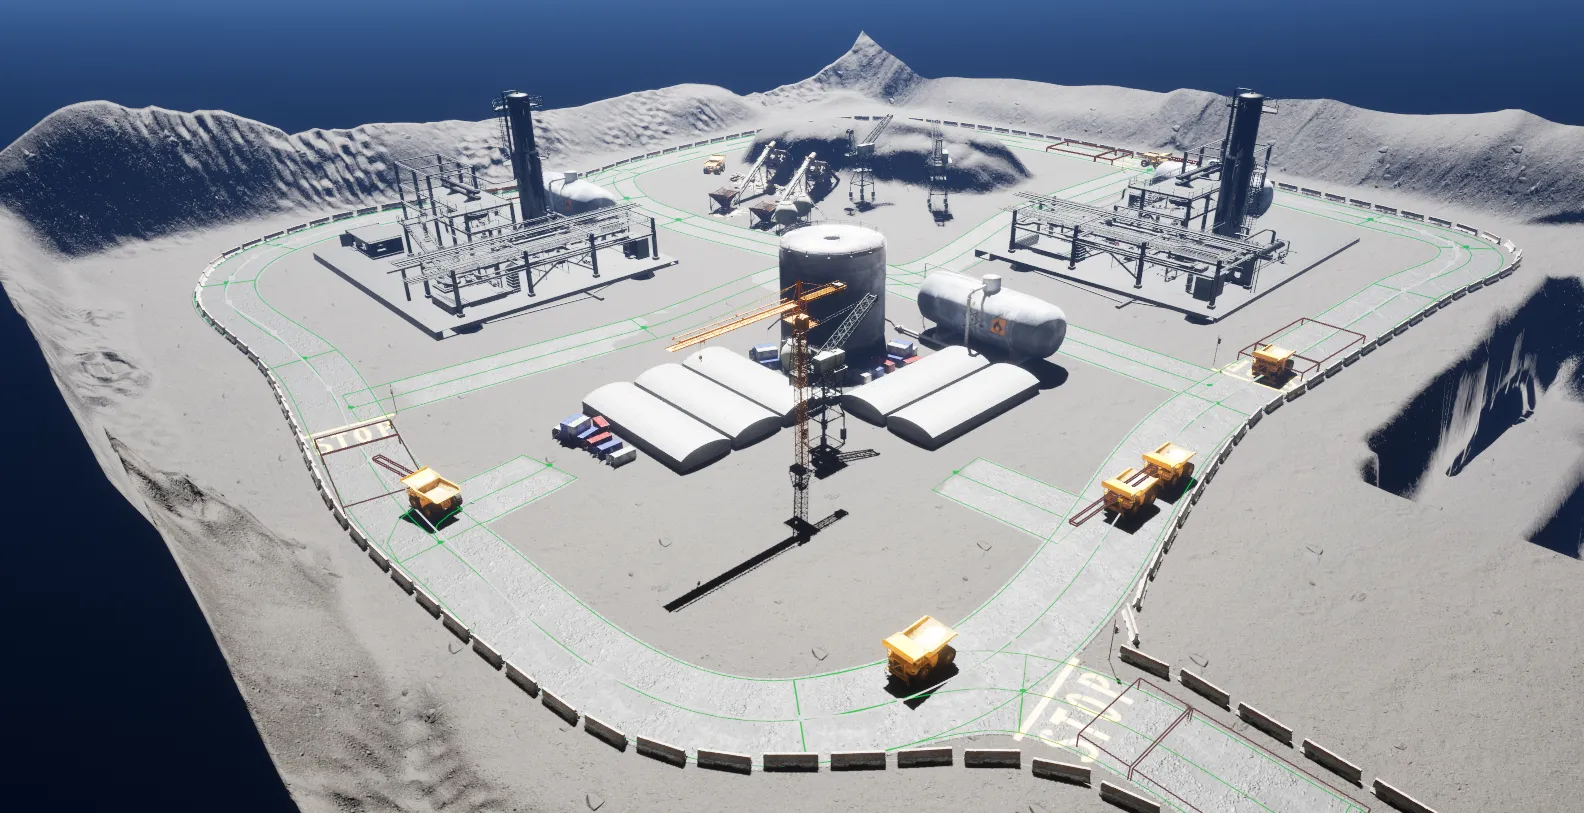
Back-end software and automation for Simulink, Unreal Engine 5 and Gazebo, including a ROS2 and UE5 driving simulator.
Hardware integration
Custom C++ libraries that capture and combine sensor data, and ROS2 links from a Logitech G29 controller into UE5.
Circuit design
Designing and prototyping electrical circuits for robotic and automated systems.
Prototyping
Soldering, 3D printing and hands-on manufacturing to turn designs into working prototypes.
AI and machine learning
Image pre-processing and data augmentation pipelines with OpenCV and NumPy, and explainable models using MTCNN and Grad-CAM.
CAD design
Detailed technical drawings and prototype models in Onshape and SolidWorks.
Programming
Python, C, C++, MATLAB, Fortran, SQL and Java, plus AI solutions built with Claude and ChatGPT.