Chess Playing Robot.
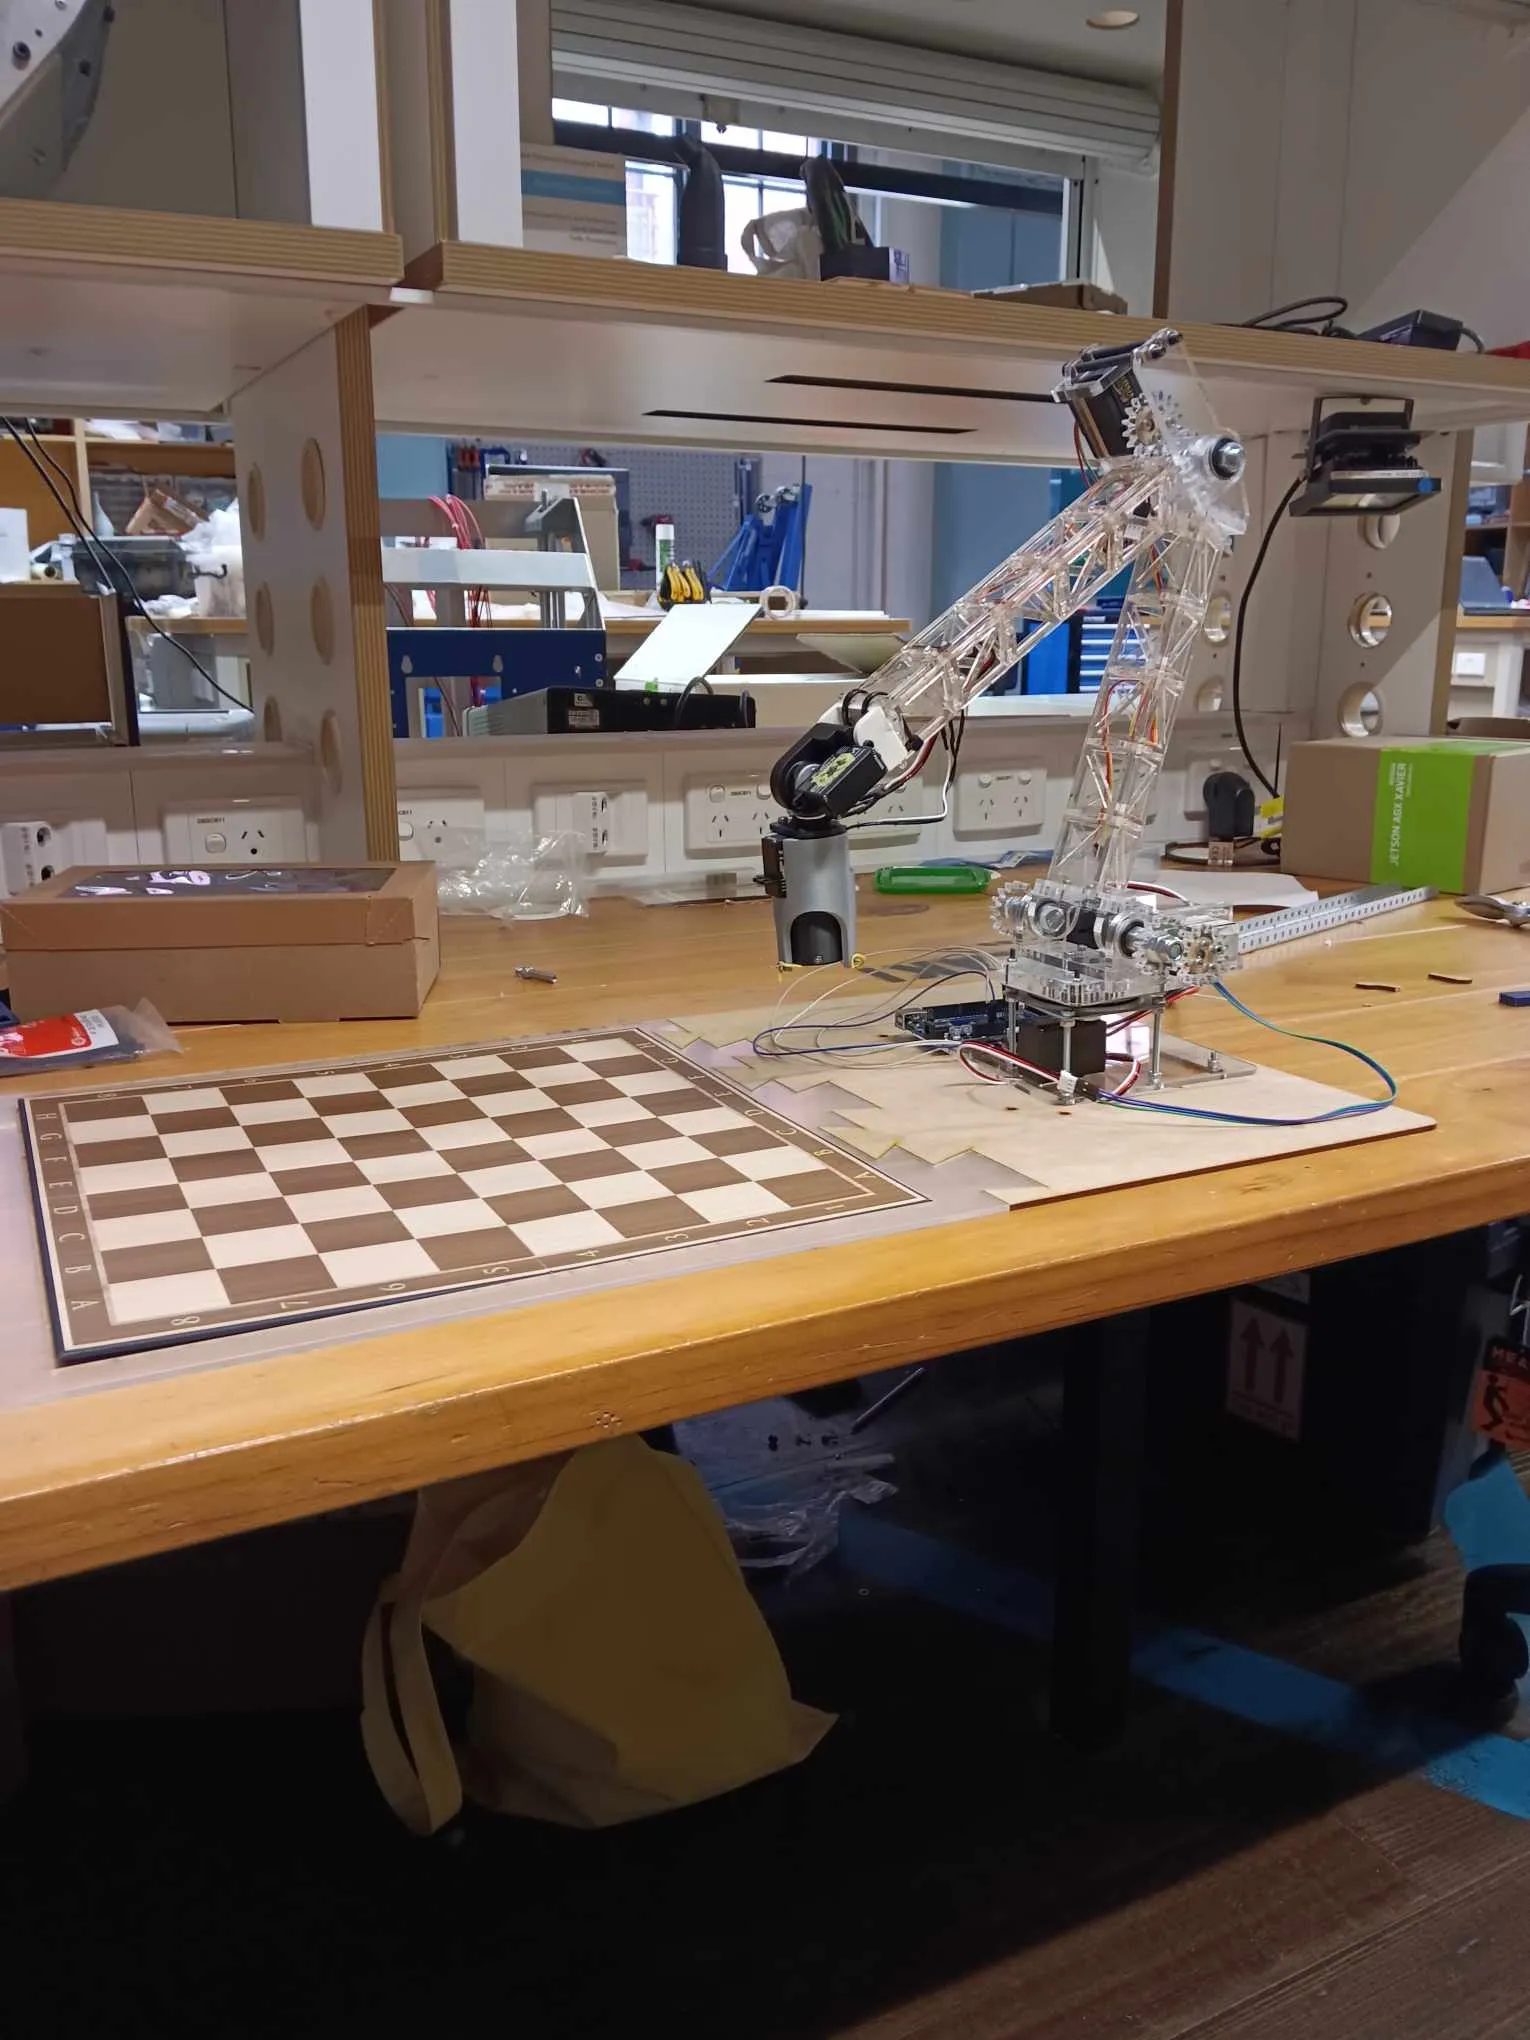
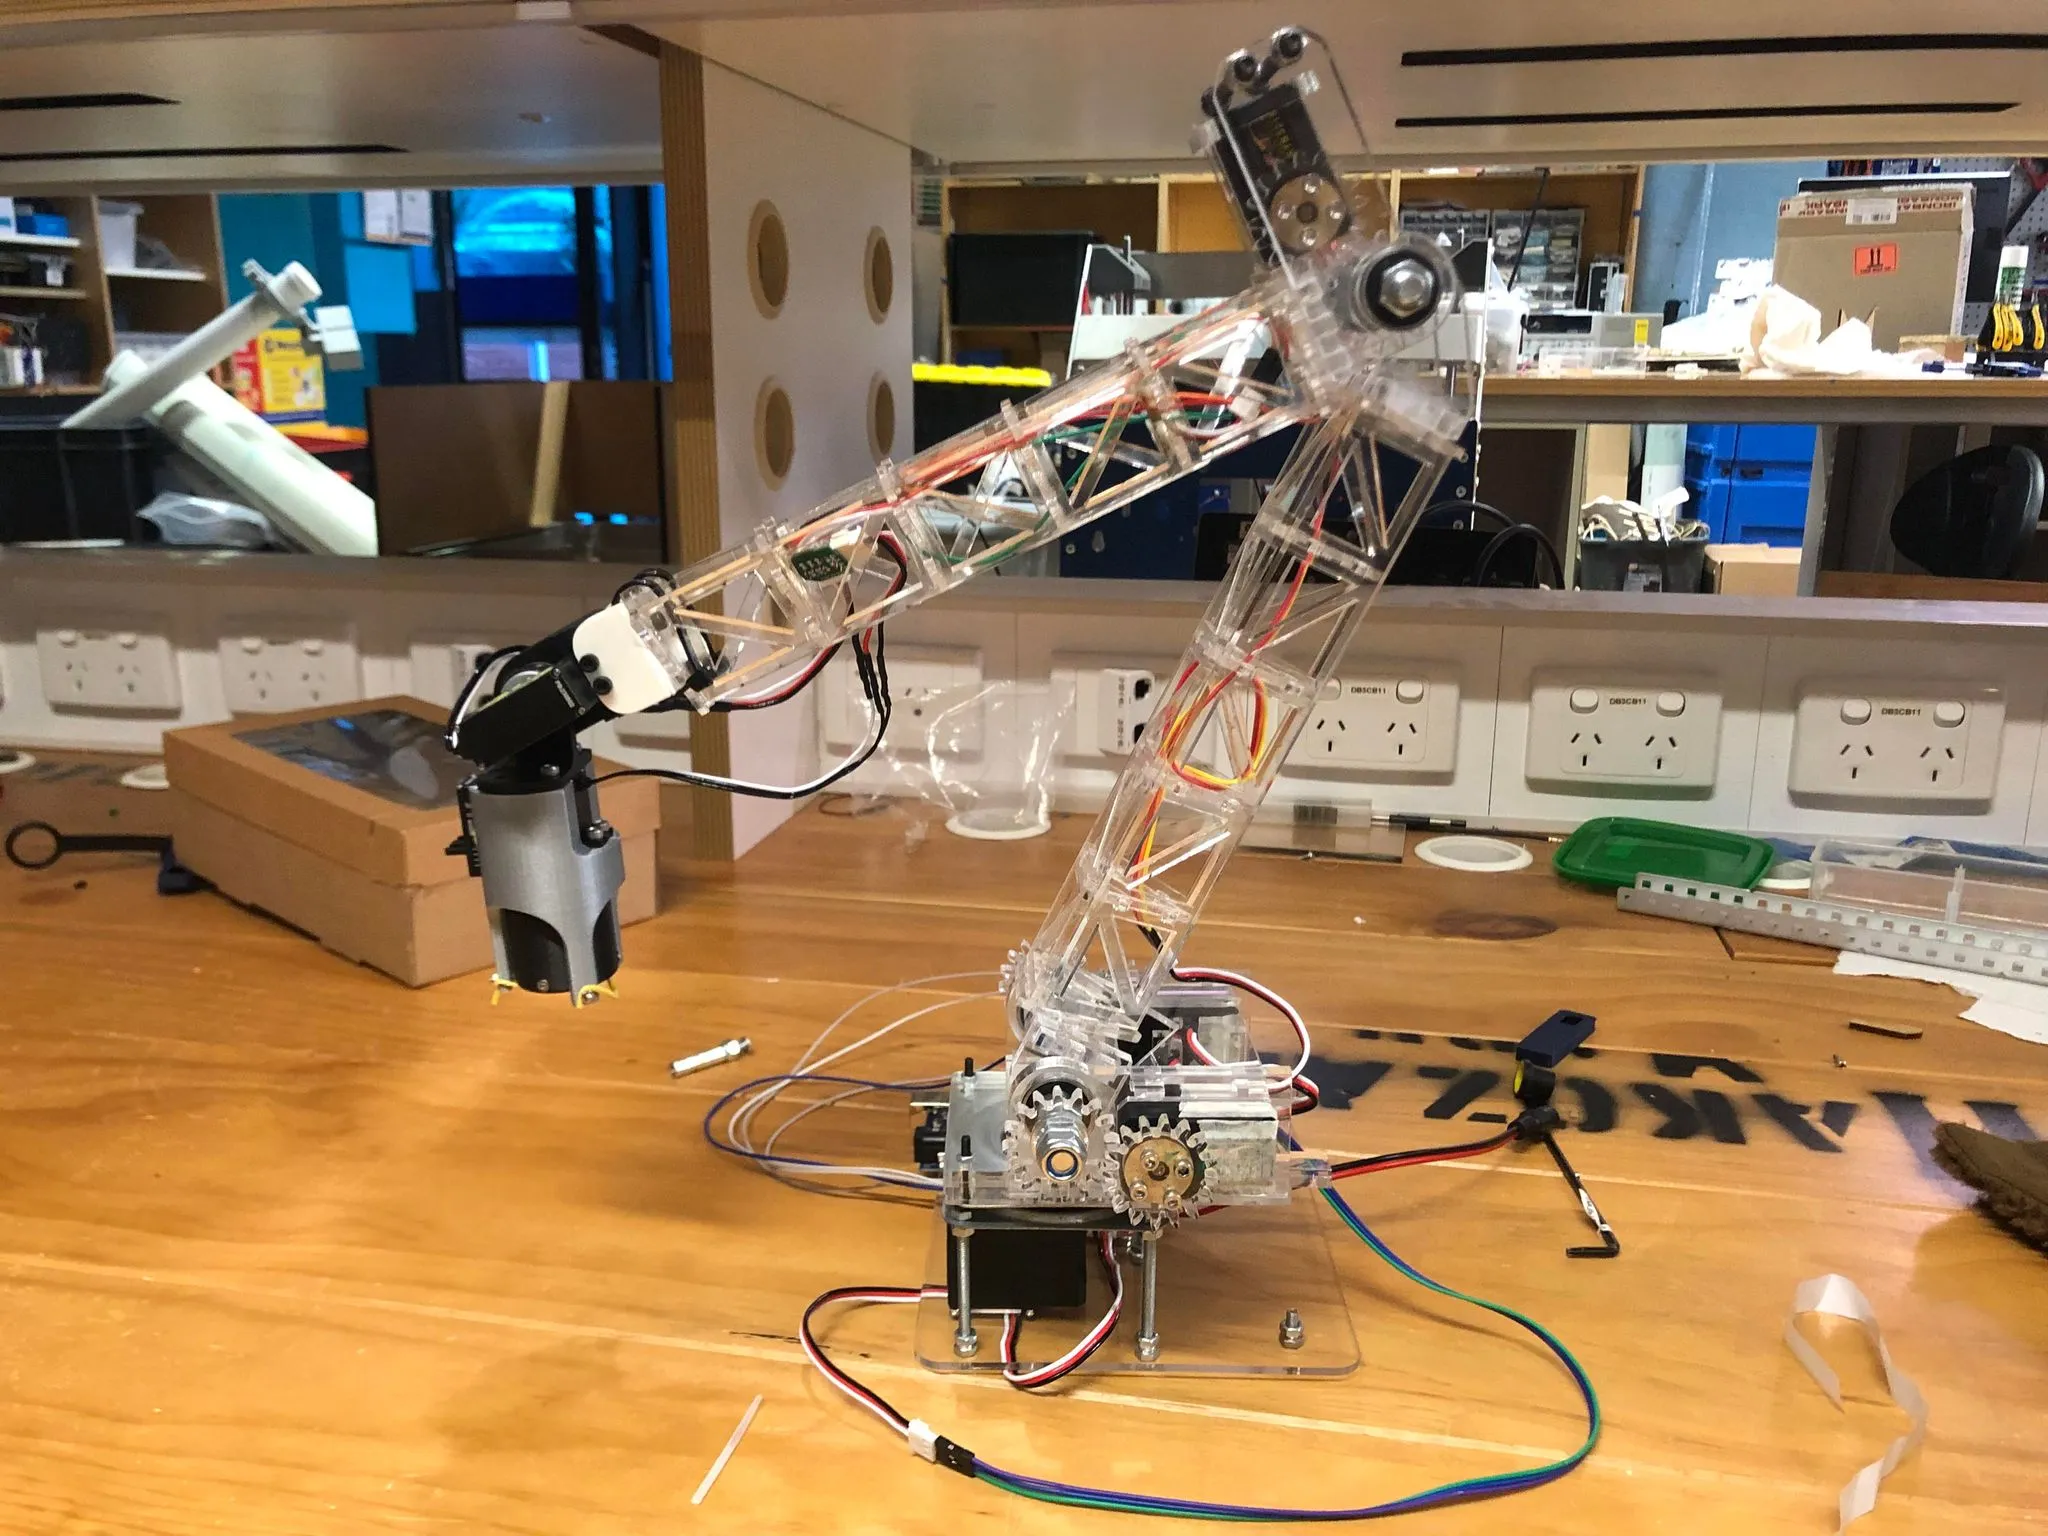
A 4-DOF robotic arm designed, built and programmed to move chess pieces, from kinematics on paper to a working machine on the bench.
Reports
Highlights
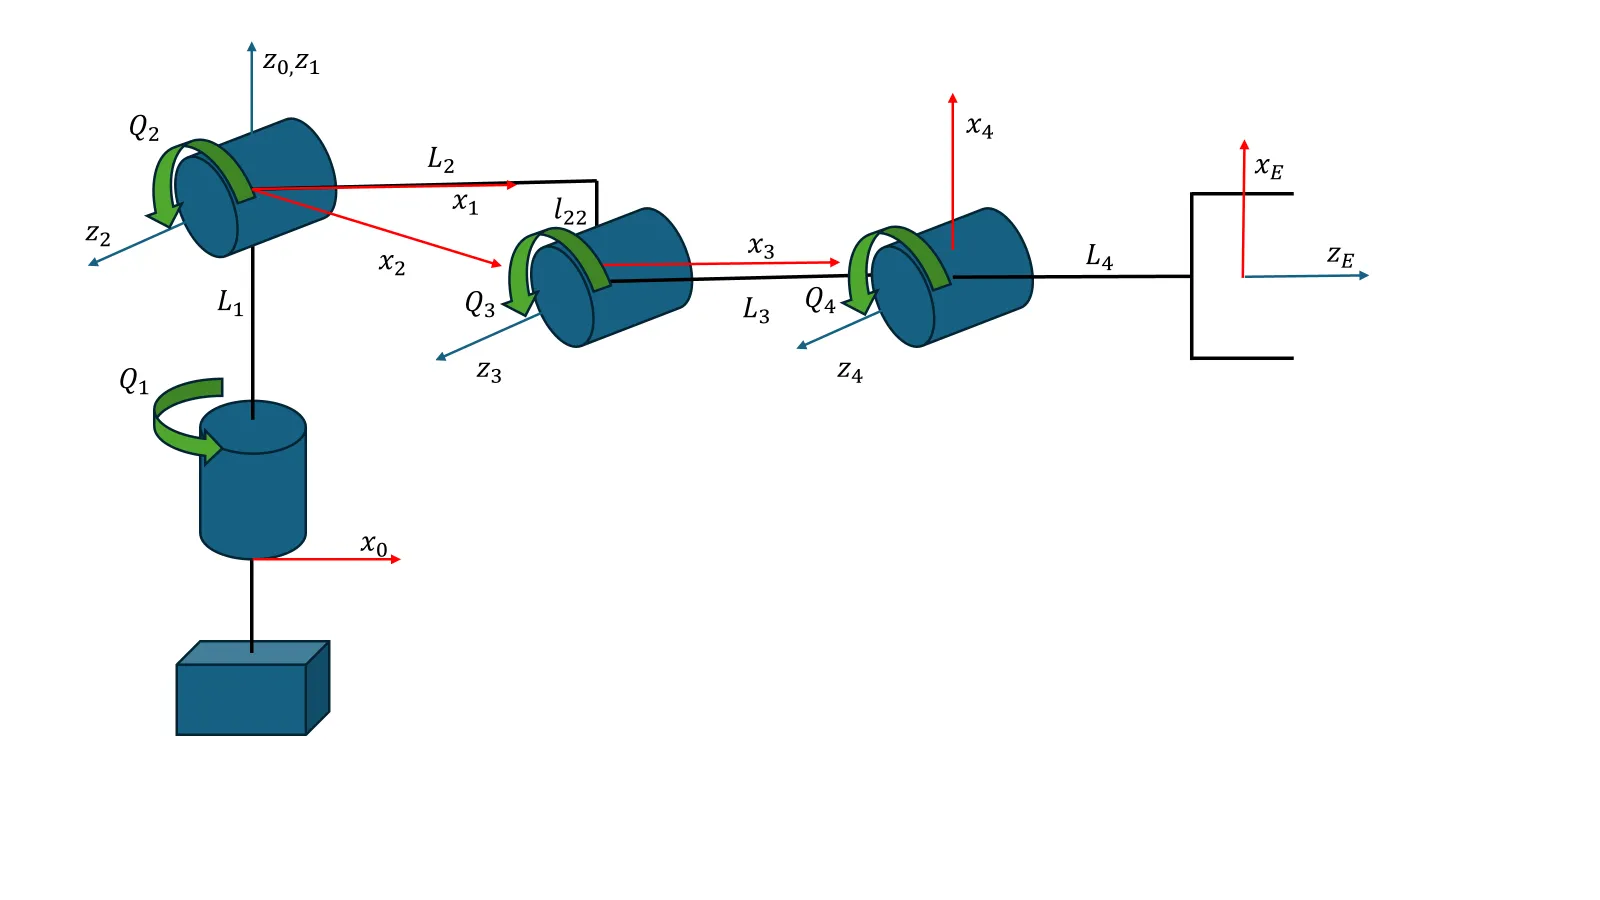
Kinematics.
Forward and inverse kinematics derived with the Denavit–Hartenberg convention, then a Jacobian relating joint velocities to end-effector motion and the torques each joint must supply.
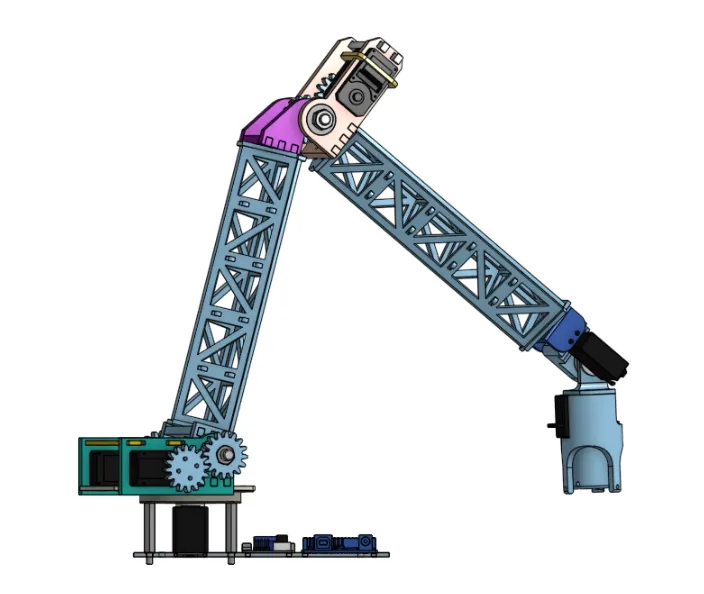
Design.
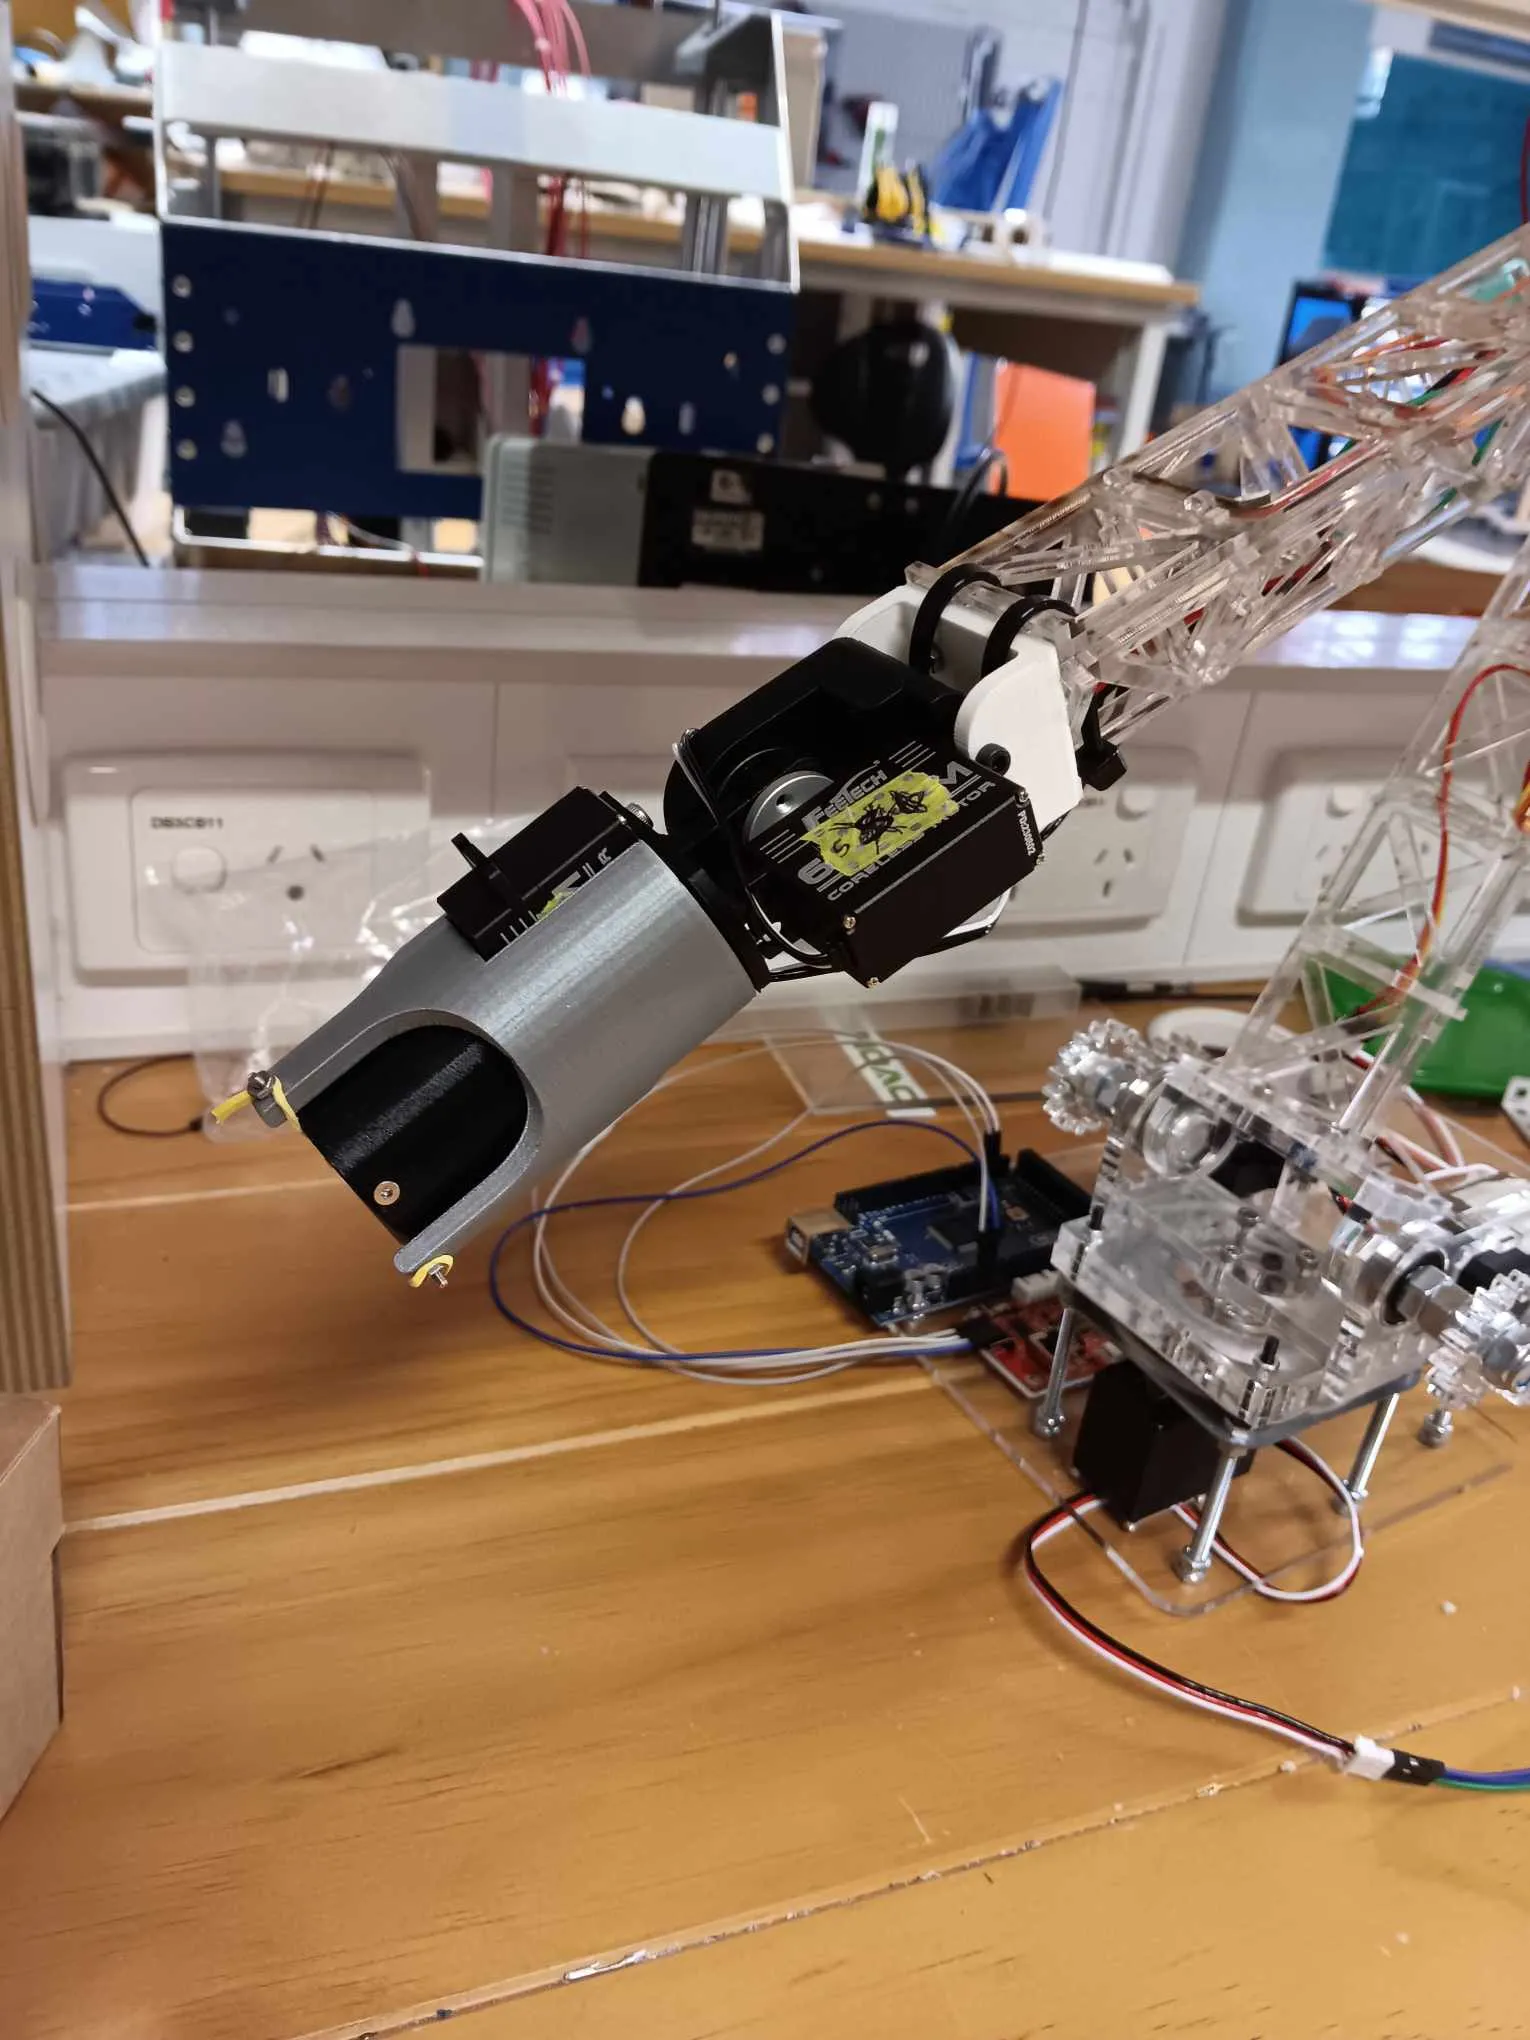
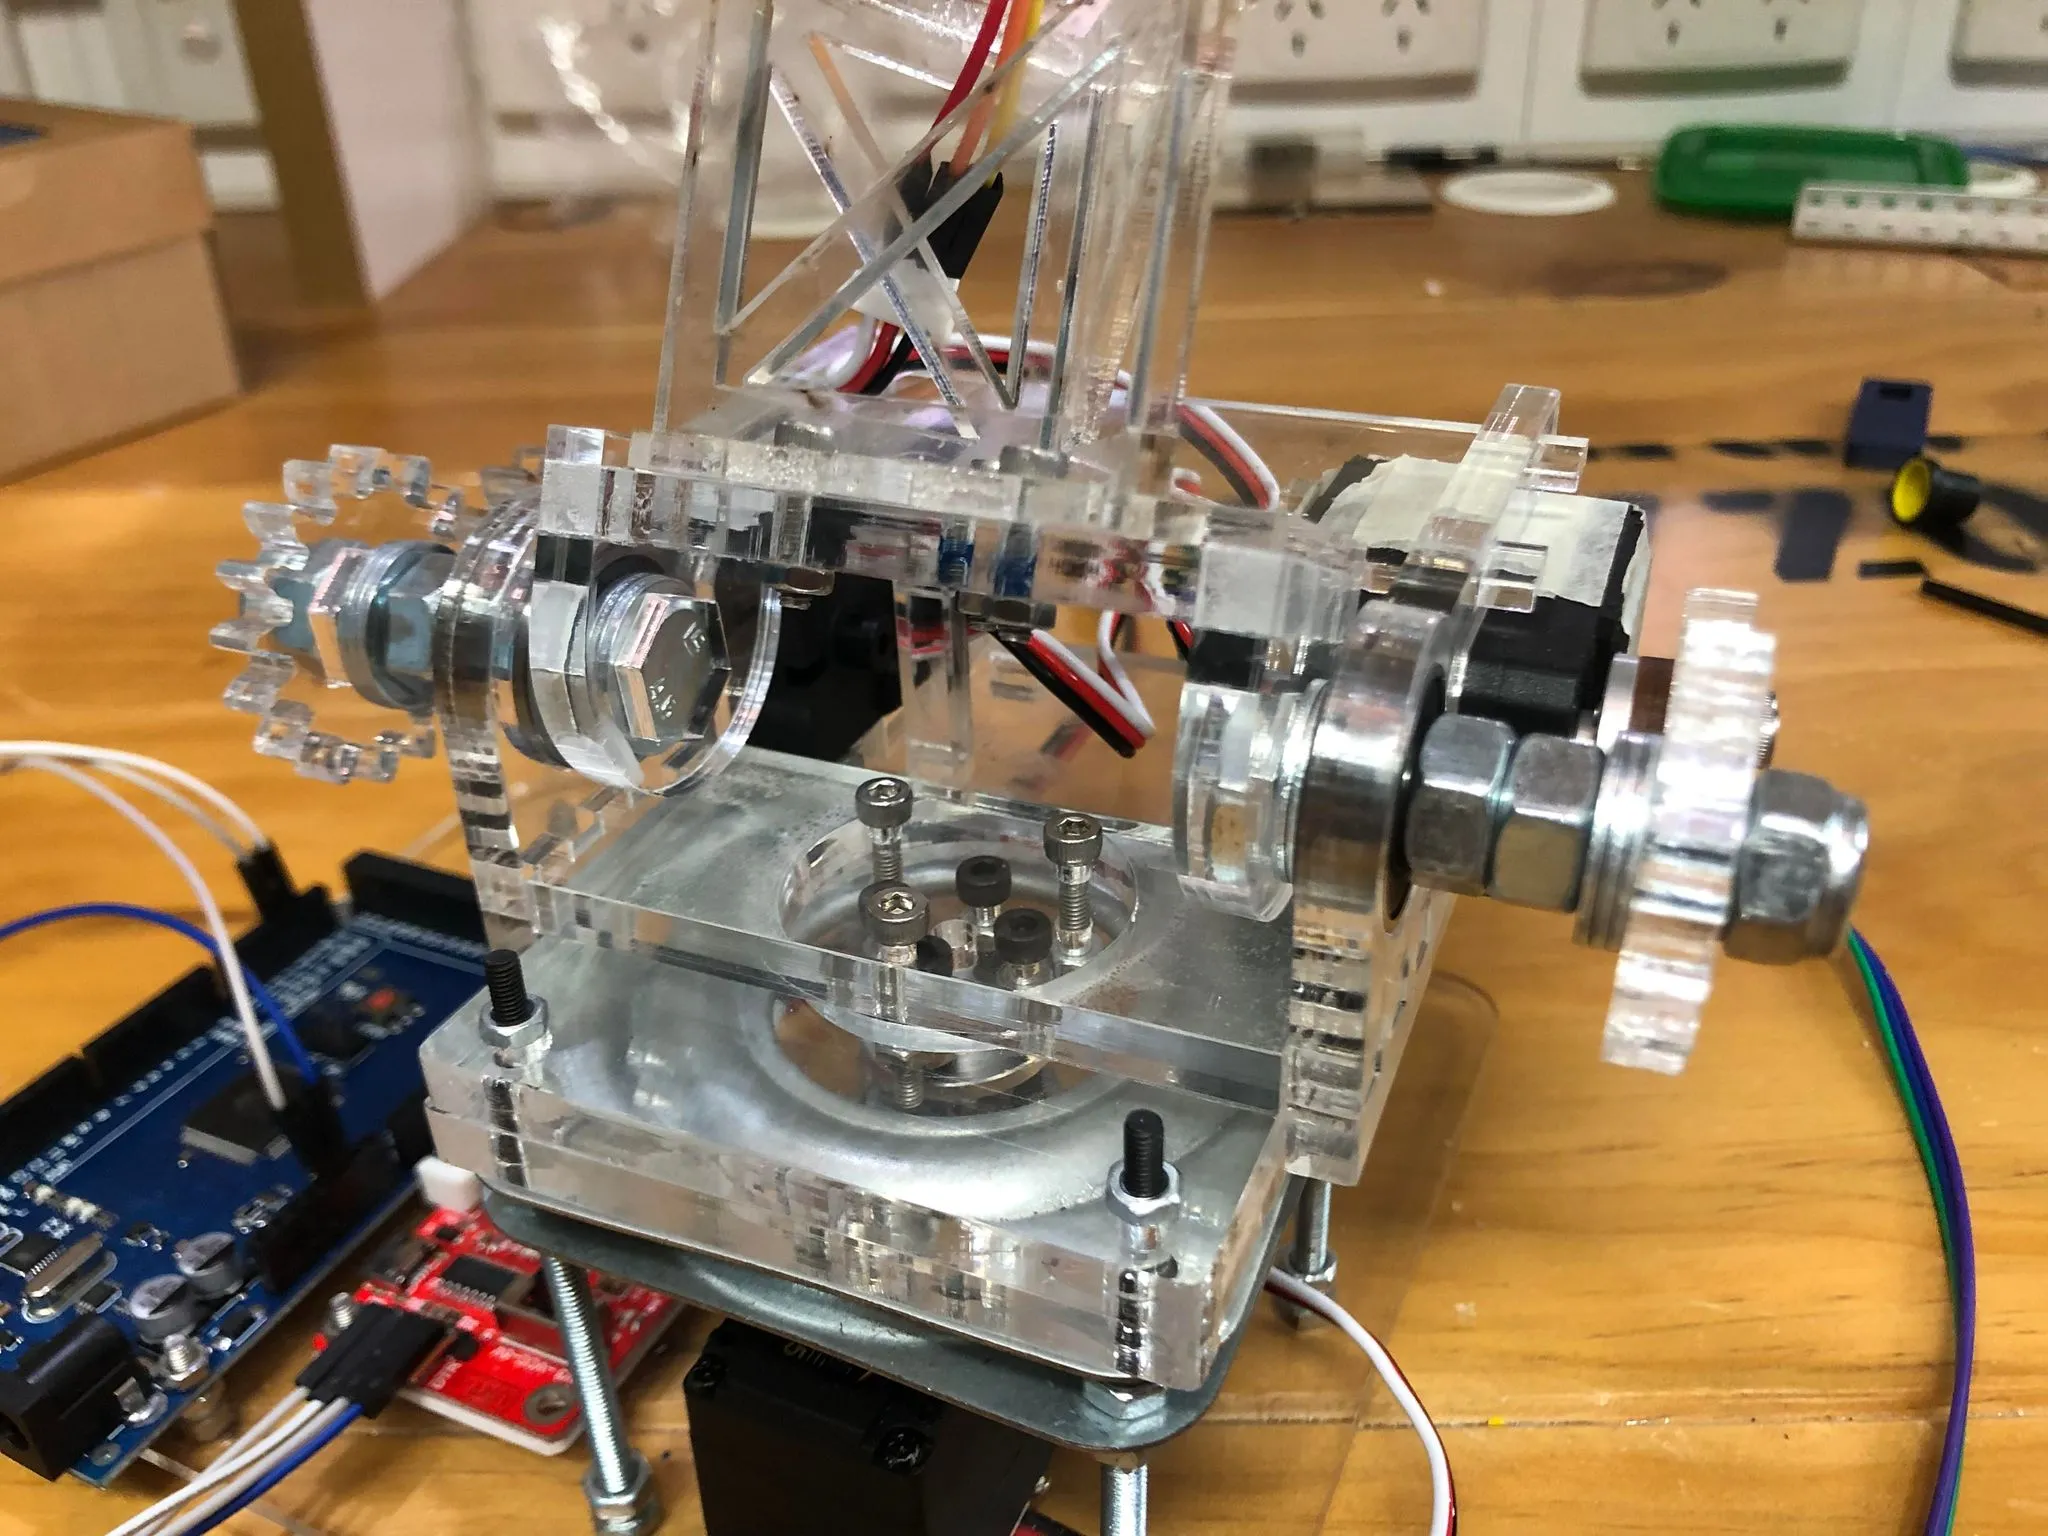
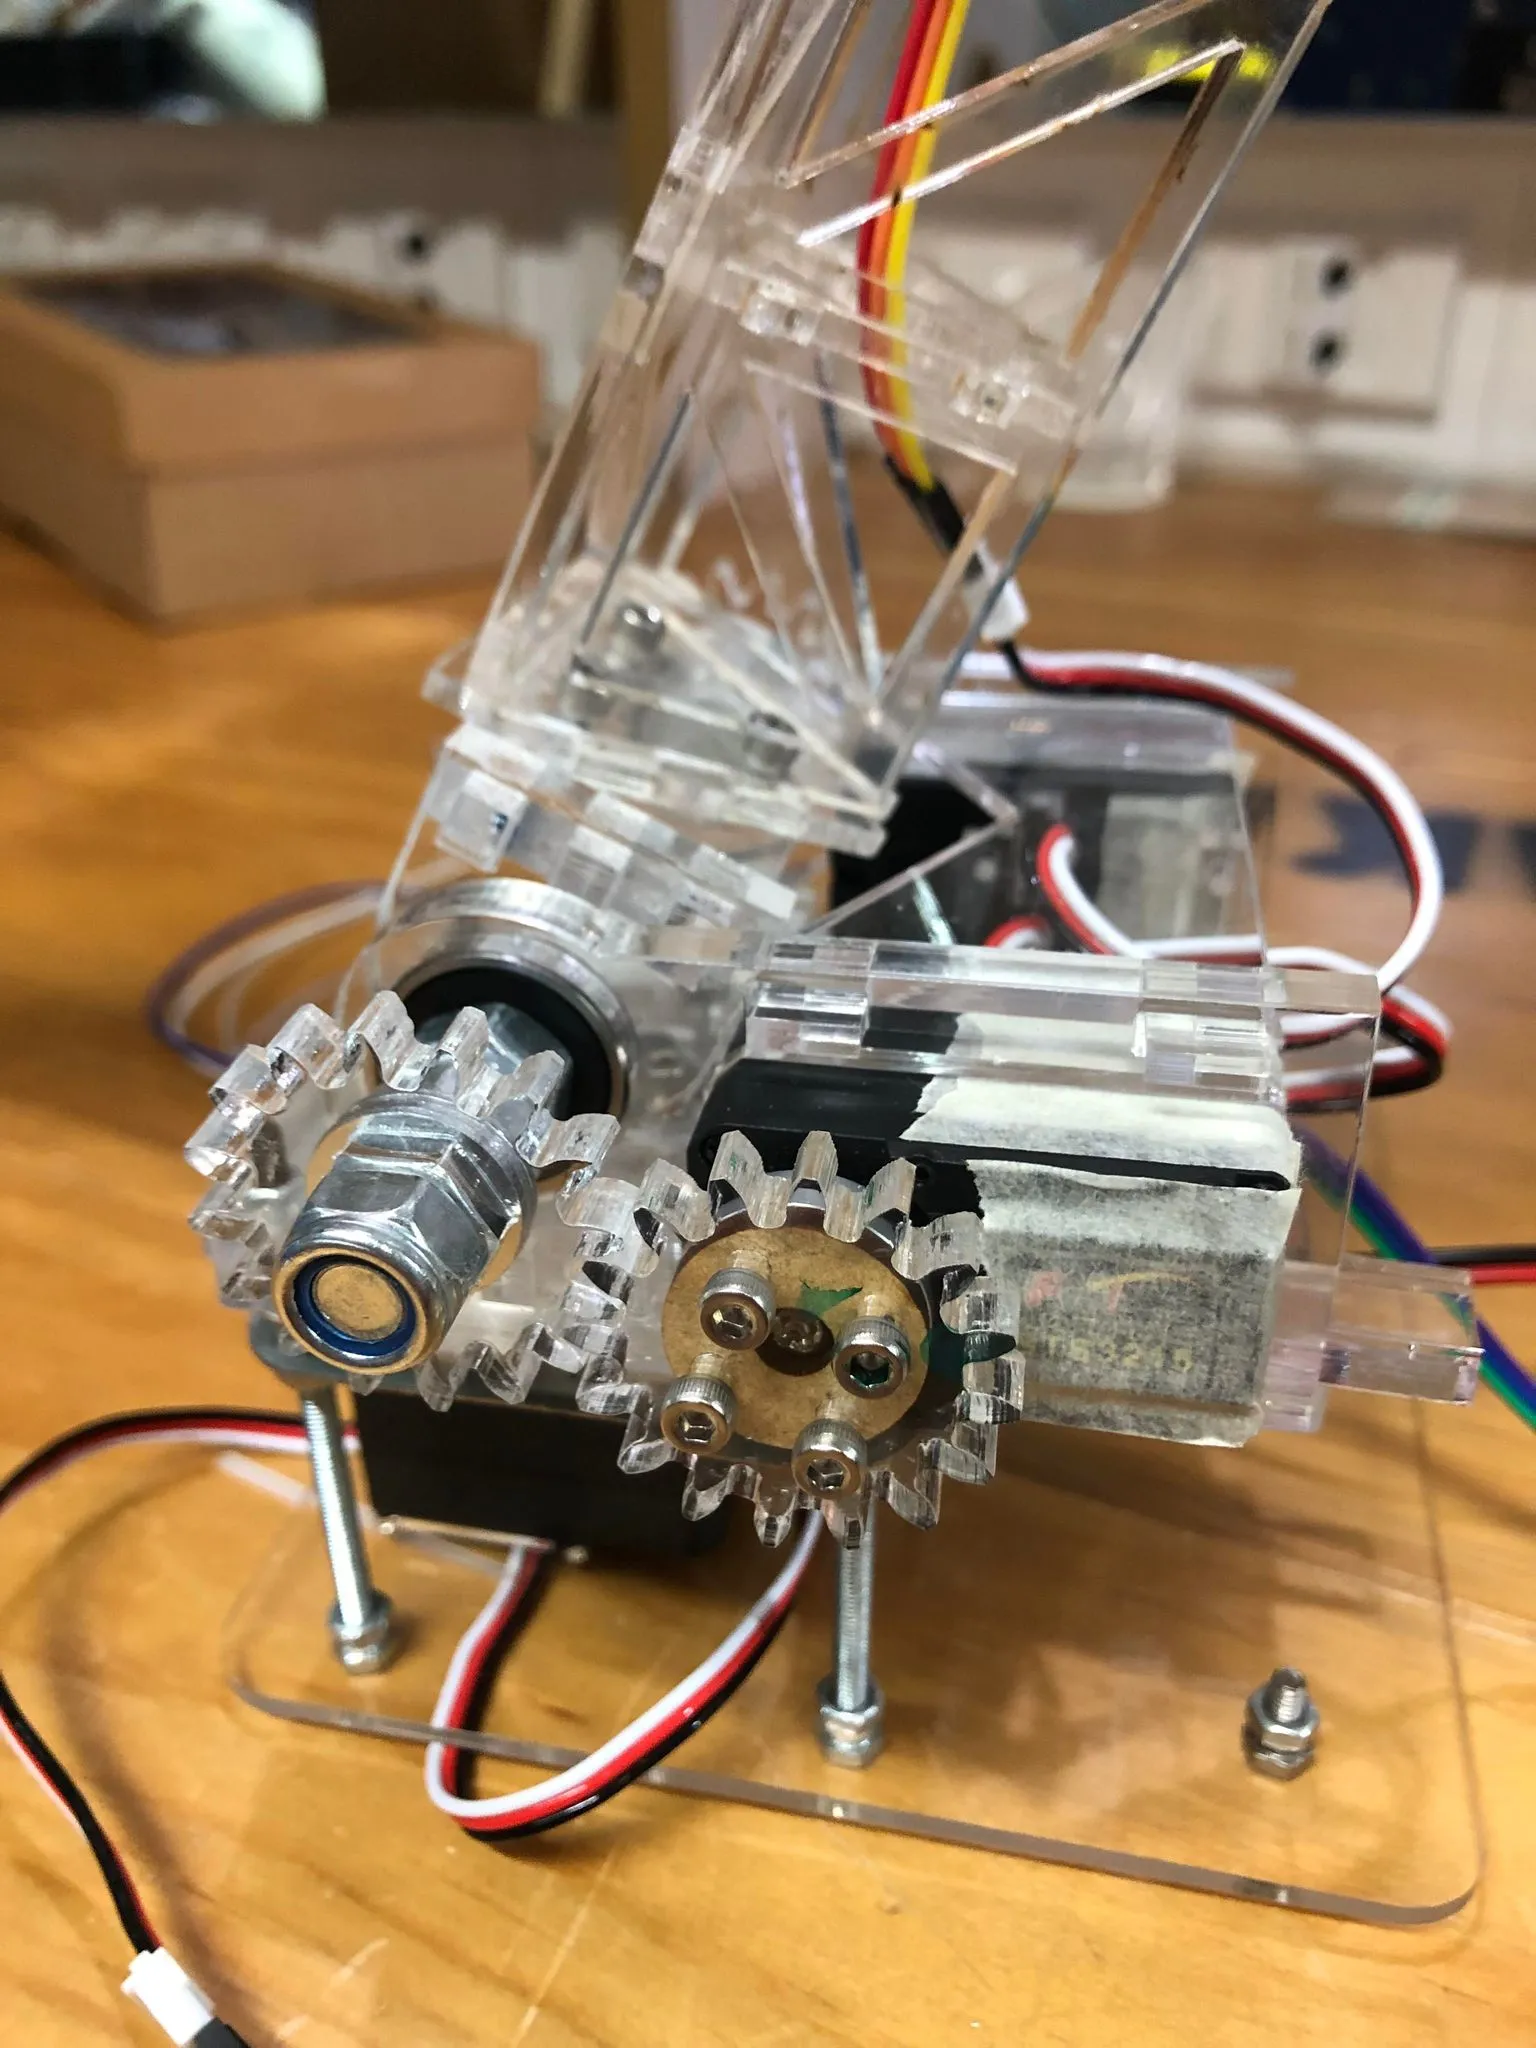
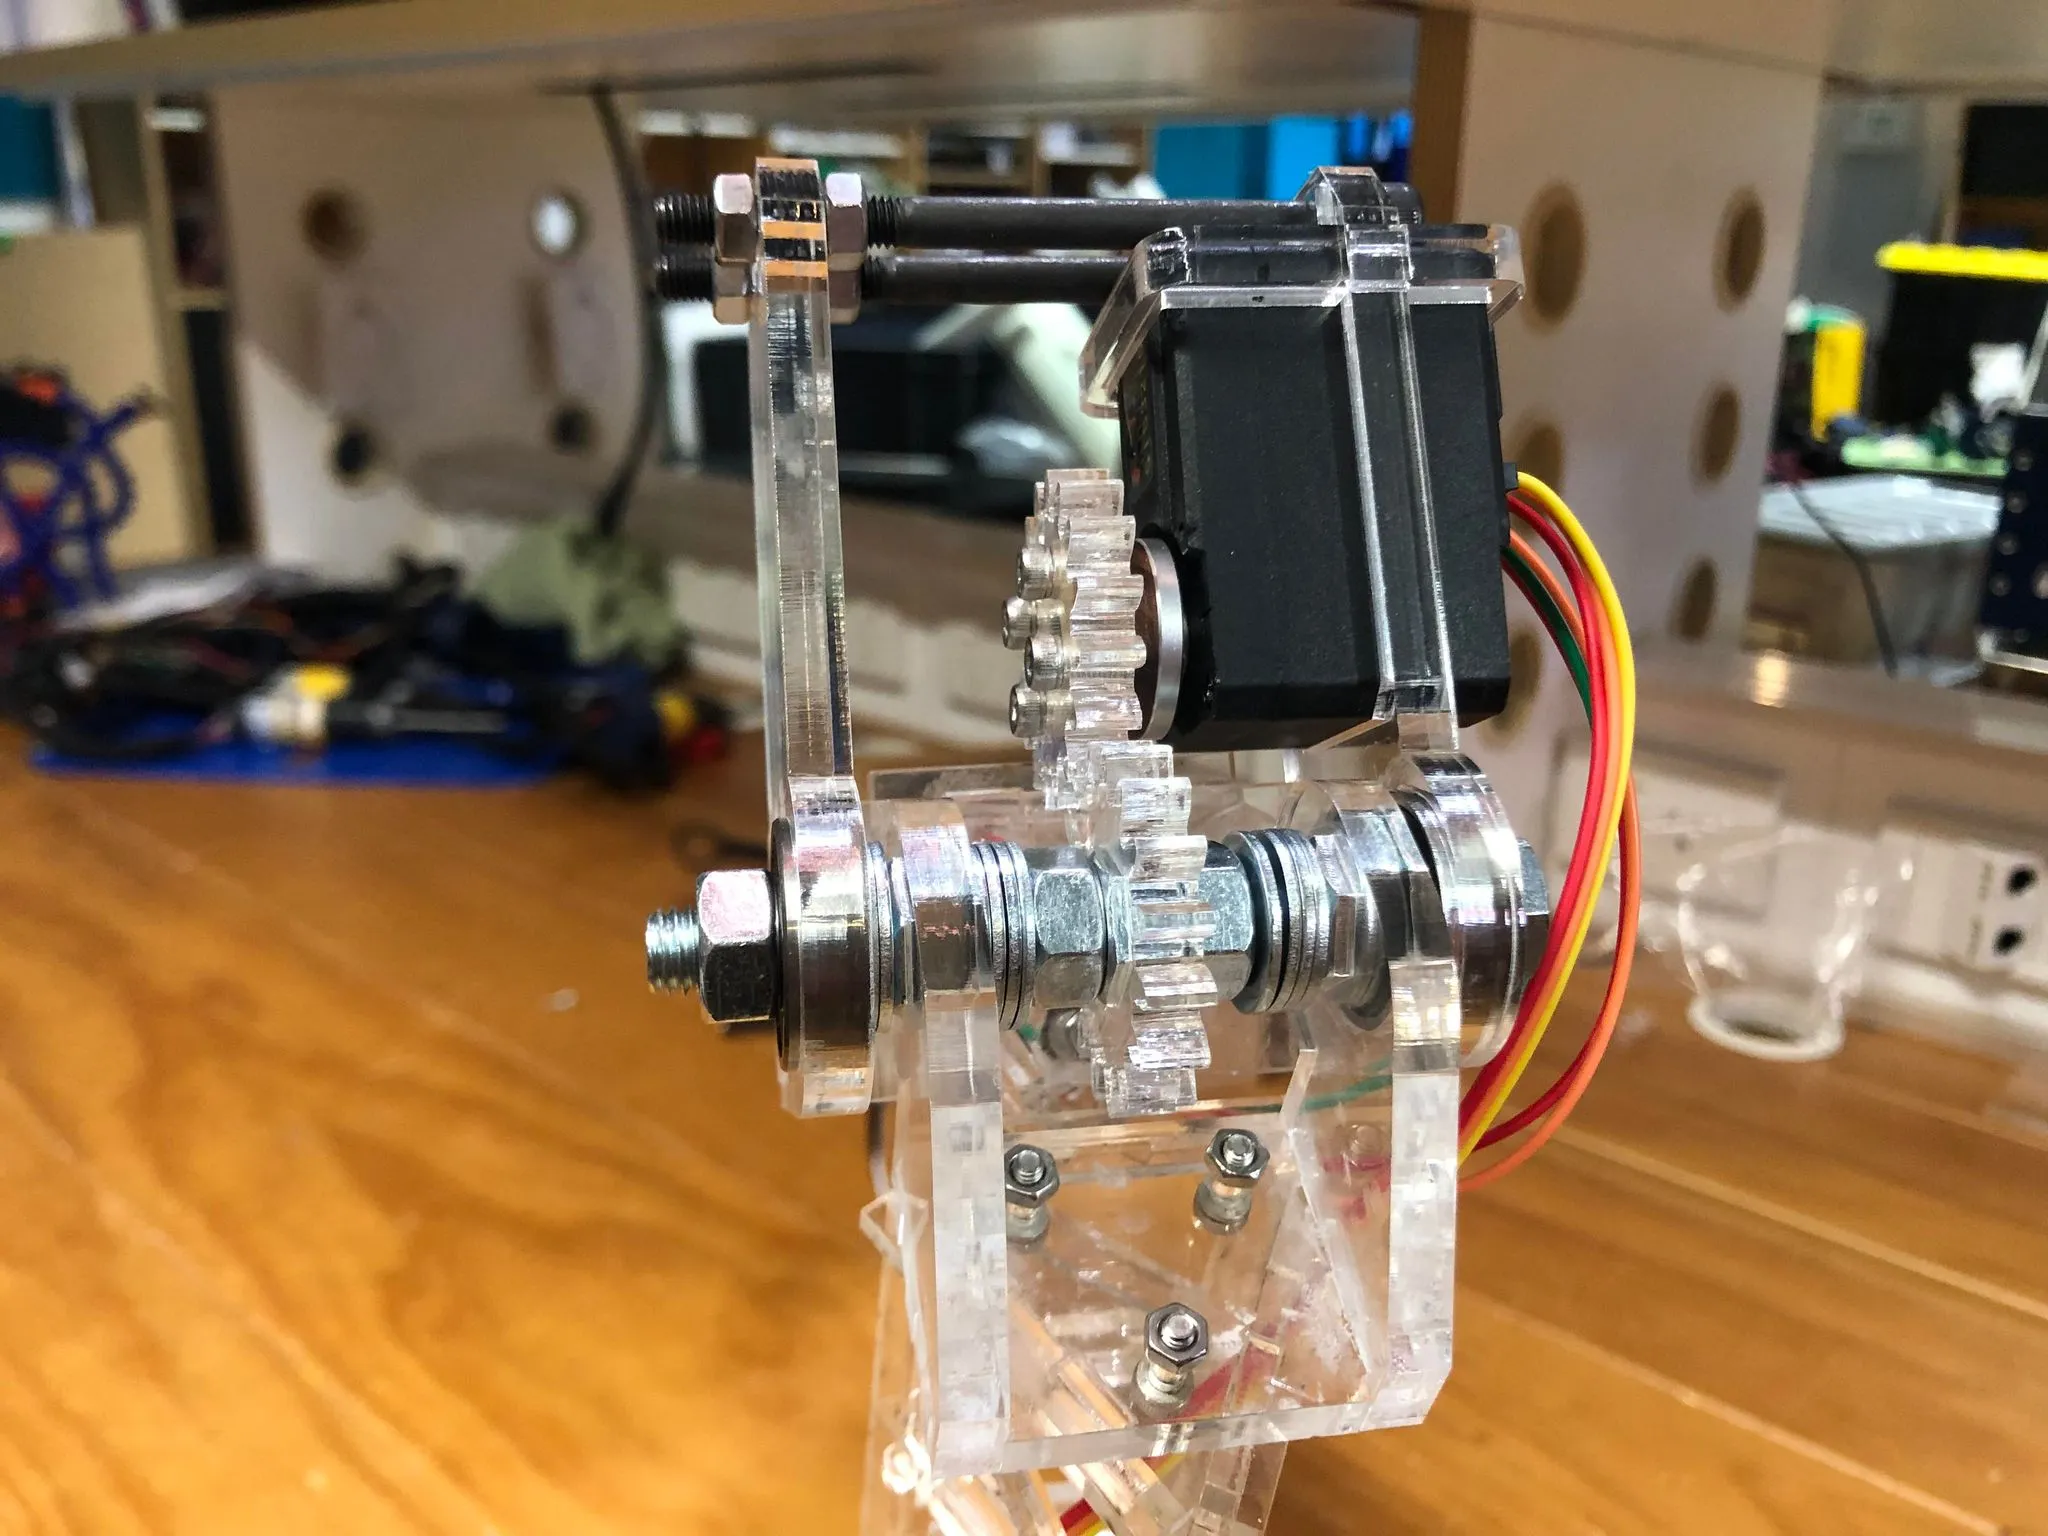
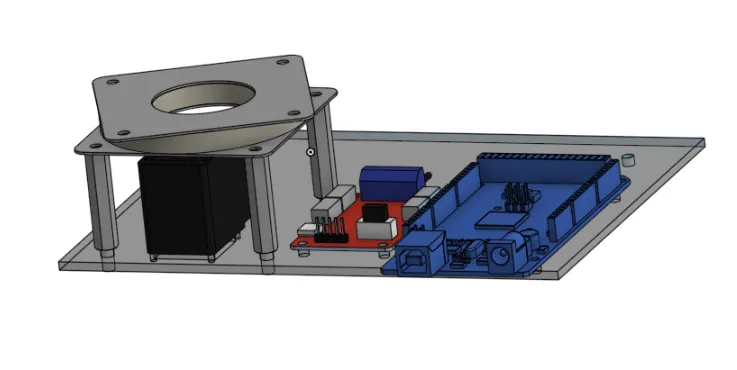
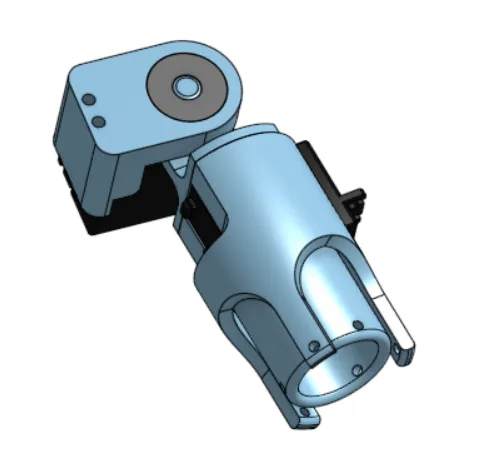
Truss-style links, a geared base and a simple, easily modified end effector, designed in CAD so parts could be remade quickly as the software matured.
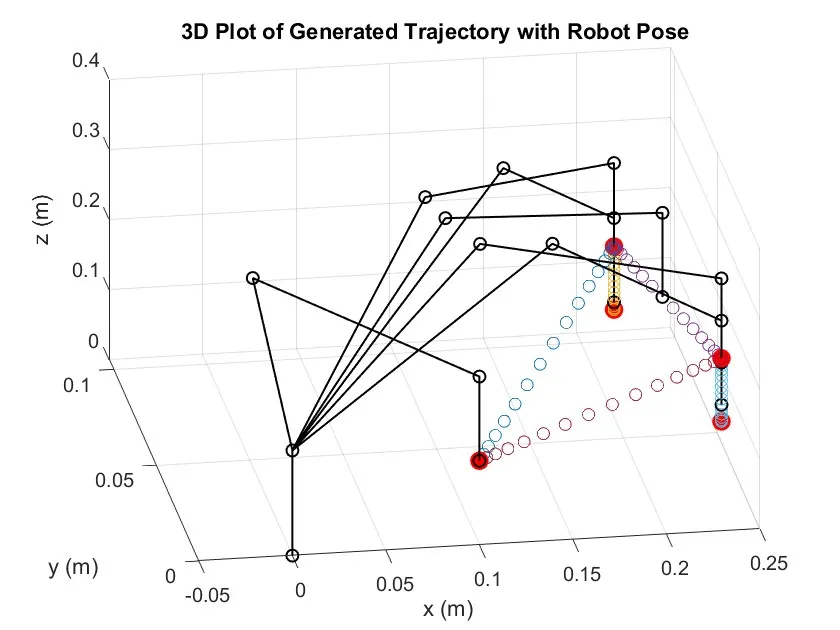
Control.
Quintic polynomial trajectories for smooth motion between poses, then task-space velocity control on the final build, with the base raised 85 mm above the board.